Uploaded July 2026 | Updated November 2026, 3 hours ago
Model Reference Control (MRC) and Model Reference Adaptive Control differ by only one word, “adaptive,” but that single word makes a major difference in practical capability.
MRAC has become a highly enabling control architecture for aerospace systems. Baseline MRC, on the other hand, can be a very risky method when applied to uncertain physical systems.
That does not mean MRC should be ignored. Understanding the assumptions, limitations, and failure modes of a control law can be just as valuable as studying a highly successful one. In many cases, the weaknesses of one method help explain why the next method was developed.
In this 45-minute lesson, I work through MRC from theory to practical assessment. We:
• derive the MRC feedback and feedforward control law
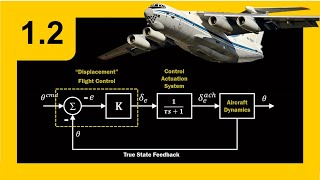
• explain how MRC attempts to replace the plant dynamics with reference-model dynamics
• derive the model-matching conditions
• compare MRC with PI and LQI control
• apply MRC to a linearized X-15 short-period model
• investigate an unexpected angle-of-attack tracking bias
• connect that bias to the Moore–Penrose pseudoinverse, projection matrices, and residual dynamics
• redesign the reference model to satisfy the matching conditions
• test sensitivity to control-effectiveness and plant-model uncertainty
• assess MRC in terms of performance, robustness, cost, and risk
The unexpected X-15 tracking bias became one of the most useful parts of the lesson. Following it through the equations provides a clearer physical interpretation of the matching conditions and shows what happens when part of the desired reference-model behavior cannot be produced through the available control input.
The broader goal is not simply to derive another controller. It is to demonstrate how a control architecture can be systematically investigated, tested, and assessed for practical aerospace application.
You can find more free guidance, navigation, and control lessons at:
LearnGandC.com
Support and gain access to codes and more: patreon.com/c/u86359827
#ControlSystems #FlightControl #AerospaceEngineering #ModelReferenceControl #GNC
Model Reference Control (MRC) and Model Reference Adaptive Control differ by only one word, “adaptive,” but that single word makes a major difference in practical capability.
MRAC has become a highly enabling control architecture for aerospace systems. Baseline MRC, on the other hand, can be a very risky method when applied to uncertain physical systems.
That does not mean MRC should be ignored. Understanding the assumptions, limitations, and failure modes of a control law can be just as valuable as studying a highly successful one. In many cases, the weaknesses of one method help explain why the next method was developed.
In this 45-minute lesson, I work through MRC from theory to practical assessment. We:
• derive the MRC feedback and feedforward control law
• explain how MRC attempts to replace the plant dynamics with reference-model dynamics
• derive the model-matching conditions
• compare MRC with PI and LQI control
• apply MRC to a linearized X-15 short-period model
• investigate an unexpected angle-of-attack tracking bias
• connect that bias to the Moore–Penrose pseudoinverse, projection matrices, and residual dynamics
• redesign the reference model to satisfy the matching conditions
• test sensitivity to control-effectiveness and plant-model uncertainty
• assess MRC in terms of performance, robustness, cost, and risk
The unexpected X-15 tracking bias became one of the most useful parts of the lesson. Following it through the equations provides a clearer physical interpretation of the matching conditions and shows what happens when part of the desired reference-model behavior cannot be produced through the available control input.
The broader goal is not simply to derive another controller. It is to demonstrate how a control architecture can be systematically investigated, tested, and assessed for practical aerospace application.
You can find more free guidance, navigation, and control lessons at:
LearnGandC.com
Support and gain access to codes and more: patreon.com/c/u86359827
#ControlSystems #FlightControl #AerospaceEngineering #ModelReferenceControl #GNC