Uploaded March 2026 | Updated November 2026, 1 day ago
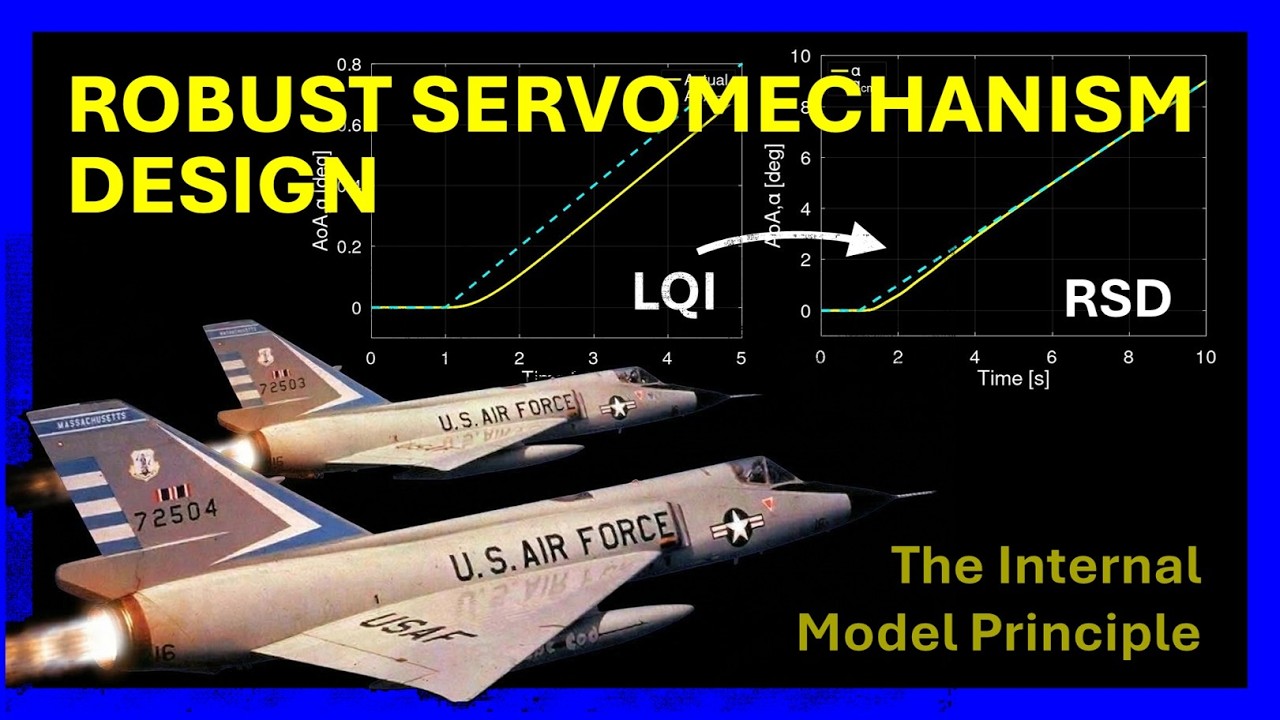
The linear quadratic integrator is a convenient technique to achieve a command tracking controller with a state feedback regulation method, like the linear quadratic regulator. However, the approach to contructing the LQI design model is ad-hoc, involving extending the plant dynamics to include integral error states of the desired tracking outputs. In our previous lesson, we showed by numerical experiment that the LQI could track a step asymtotically, even when a step disturance was added to the plant. However, the LQI fails to produce asymptotic tracking of ramps, sinusoids, or other types of signals, no matter how large the gains are tuned.
The reason behind these observations is that when we construct the LQI design model, we embed a specific internal model for the command to be tracked. The idea of embedding internal models for command tracking is called the internal model principle and a systematic method to incorporate internal models is called the robust servomechanism design.
In this lesson, we motivate the internal model principle with the limitations of the LQI. We then derive the robust servomechanism design model, and outline a control design method involving the RSD and the linear quadratic regulator. The result is a process that enables the user to embed a wide range of internal models described by differential equations for the command input, enabling closed loop asymptotic tracking. An example showing asymptotic tracking of a ramp is provided. Why tracking higher order signals in flight control systems of aircraft is not common is discussed.
Access this lesson and more at: LearnGandC.com
LearnGandC.com and this lesson is brought to you by Patreon subscribers to Learn Guidance and Control. A special thank you to all subscribers
Get the codes in this lesson and all my previous lessons at: patreon.com/c/u86359827
#flightcontrol #aerospaceengineering #flightsimulation #controltheory
The linear quadratic integrator is a convenient technique to achieve a command tracking controller with a state feedback regulation method, like the linear quadratic regulator. However, the approach to contructing the LQI design model is ad-hoc, involving extending the plant dynamics to include integral error states of the desired tracking outputs. In our previous lesson, we showed by numerical experiment that the LQI could track a step asymtotically, even when a step disturance was added to the plant. However, the LQI fails to produce asymptotic tracking of ramps, sinusoids, or other types of signals, no matter how large the gains are tuned.
The reason behind these observations is that when we construct the LQI design model, we embed a specific internal model for the command to be tracked. The idea of embedding internal models for command tracking is called the internal model principle and a systematic method to incorporate internal models is called the robust servomechanism design.
In this lesson, we motivate the internal model principle with the limitations of the LQI. We then derive the robust servomechanism design model, and outline a control design method involving the RSD and the linear quadratic regulator. The result is a process that enables the user to embed a wide range of internal models described by differential equations for the command input, enabling closed loop asymptotic tracking. An example showing asymptotic tracking of a ramp is provided. Why tracking higher order signals in flight control systems of aircraft is not common is discussed.
Access this lesson and more at: LearnGandC.com
LearnGandC.com and this lesson is brought to you by Patreon subscribers to Learn Guidance and Control. A special thank you to all subscribers
Get the codes in this lesson and all my previous lessons at: patreon.com/c/u86359827
#flightcontrol #aerospaceengineering #flightsimulation #controltheory