Uploaded October 2017 | Updated September 2026, 2 weeks ago
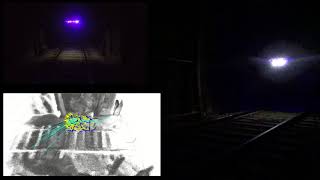
This video presents results on autonomous exploration and mapping of tunnel environments using the developed Multi-Modal Mapping Unit (M3U). The M3U tightly synchronized a stereo camera pair with an Inertial Measurement Unit and super-bright flashing LEDs, while it further fuses time-of-flight 3D depth sensors. It allows for GPS-denied localization and mapping visually-degraded environments, an ability that is then combined with autonomous exploration path planning.
For more please visit: autonomousrobotslab.com
This video presents results on autonomous exploration and mapping of tunnel environments using the developed Multi-Modal Mapping Unit (M3U). The M3U tightly synchronized a stereo camera pair with an Inertial Measurement Unit and super-bright flashing LEDs, while it further fuses time-of-flight 3D depth sensors. It allows for GPS-denied localization and mapping visually-degraded environments, an ability that is then combined with autonomous exploration path planning.
For more please visit: autonomousrobotslab.com