Uploaded June 2023 | Updated September 2026, 5 minutes ago
This is the video of Fredy Maeder's bachelor thesis in spring 2023 at the computer science department of the Bern University of Applied Sciences in Switzerland.
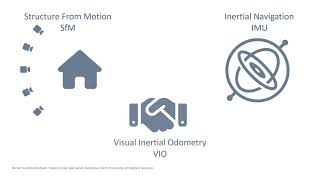
A system based on Visual Inertial Odometry has been developed for GPS-free navigation of a drone. For this purpose, the Structure from Motion technology was adopted from the preliminary study and additionally combined with inertial navigation. The implementation reconstructs a path that was completed with a smartphone. The data collection is done with an Android application, which was developed especially for this application.
OpenCV was used to implement a Structure from Motion, which computes a relative 3D path from multiple 2D camera images. This path is scale-less. The problem of the missing scale was tried to be solved by inertial navigation. Accelerations are measured continuously during the movement. By a double integration of these data, a covered distance can be inferred.
Finally, both signals were merged and converted to a path in geocoordinates. This could be compared with additionally measured GPS data. The drift of the measured acceleration data falsifies the data as expected. Better acceleration sensors could bring an improvement here. Nevertheless, plausible calculations could be performed.
This is the video of Fredy Maeder's bachelor thesis in spring 2023 at the computer science department of the Bern University of Applied Sciences in Switzerland.
A system based on Visual Inertial Odometry has been developed for GPS-free navigation of a drone. For this purpose, the Structure from Motion technology was adopted from the preliminary study and additionally combined with inertial navigation. The implementation reconstructs a path that was completed with a smartphone. The data collection is done with an Android application, which was developed especially for this application.
OpenCV was used to implement a Structure from Motion, which computes a relative 3D path from multiple 2D camera images. This path is scale-less. The problem of the missing scale was tried to be solved by inertial navigation. Accelerations are measured continuously during the movement. By a double integration of these data, a covered distance can be inferred.
Finally, both signals were merged and converted to a path in geocoordinates. This could be compared with additionally measured GPS data. The drift of the measured acceleration data falsifies the data as expected. Better acceleration sensors could bring an improvement here. Nevertheless, plausible calculations could be performed.