Vision-based (no motion capture) estimation, control and planning for small quadrotors_old @KumarLabPenn
Vision-based (no motion capture) estimation, control and planning for small quadrotors_old  @KumarLabPenn
Uploaded September 2014 | Updated November 2026, 1 day ago
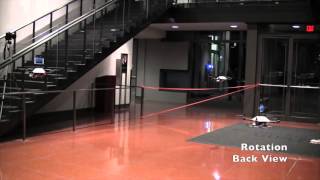
This video illustrates how a single camera and an IMU can be used together with a textured carpet marked with April tags to navigate in indoor environments without motion capture cameras. Work done by Shaojie Shen.
Vision-based (no motion capture) estimation, control and planning for small quadrotors_oldDevices, Systems, and Methods for Automated Monitoring enabling Precision AgricultureAny Way You Look at It: Semantic Crossview Localization and Mapping With LiDARPlanning and Control of Aggresive Maneuvers for Perching on Inclined and Vertical SurfacesVision-based Multi-MAV Localization with Anonymous Relative Measurements Using CPDAF FilterA Swarm of Flying Phones (CES 2016)Toward Soft Micro Bio Robots for Cellular and Chemical DeliveryTrajectory Optimization with Global Yaw Parameterization for FOV Constrained Autonomous FlightAutonomous Flight for Detection, Localization, and Tracking of Moving Targets With a Small QuadrotorInformation-Theoretic Mapping Using Cauchy-Schwarz Quadratic Mutual InformationAutonomous Quadrotor Flight Based On Googles Project TangoActive Metric-Semantic Mapping by Multiple Aerial Robots
Vijay Kumar |

Vision-based (no motion capture) estimation, control and planning for small quadrotors_old

SHARE TO X SHARE TO REDDIT SHARE TO FACEBOOK WALLPAPER