Uploaded June 2015 | Updated November 2026, 24 minutes ago
Video description of work to be presented at IEEE International Conference on Automation Science and Engineering (IEEE CASE 2015) in Gothenburg, Sweden, August 24 to 28, 2015.
"Devices, Systems, and Methods for Automated Monitoring enabling Precision Agriculture"
Abstract:
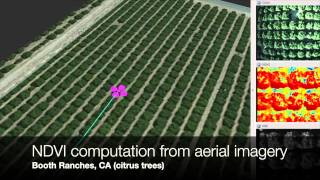
Addressing the challenges of feeding the burgeon- ing world population with limited resources requires innovation in sustainable, efficient farming. The practice of precision agriculture offers many benefits towards addressing these challenges, such as improved yield and efficient use of such resources as water, fertilizer and pesticides. We describe the design and development of a light-weight, multi-spectral 3D imaging device that can be used for automated monitoring in precision agriculture. The sensor suite consists of a laser range scanner, multi-spectral cameras, a thermal imaging camera, and navigational sensors. We present techniques to extract four key data products—plant morphology, canopy volume, leaf area index, and fruit counts—using the sensor suite. We demonstrate its use with two systems: multi-rotor micro aerial vehicles and on a human-carried, shoulder-mounted harness. We show results of field experiments conducted in collaboration with growers and agronomists in vineyards, apple orchards and orange groves.
Video description of work to be presented at IEEE International Conference on Automation Science and Engineering (IEEE CASE 2015) in Gothenburg, Sweden, August 24 to 28, 2015.
"Devices, Systems, and Methods for Automated Monitoring enabling Precision Agriculture"
Abstract:
Addressing the challenges of feeding the burgeon- ing world population with limited resources requires innovation in sustainable, efficient farming. The practice of precision agriculture offers many benefits towards addressing these challenges, such as improved yield and efficient use of such resources as water, fertilizer and pesticides. We describe the design and development of a light-weight, multi-spectral 3D imaging device that can be used for automated monitoring in precision agriculture. The sensor suite consists of a laser range scanner, multi-spectral cameras, a thermal imaging camera, and navigational sensors. We present techniques to extract four key data products—plant morphology, canopy volume, leaf area index, and fruit counts—using the sensor suite. We demonstrate its use with two systems: multi-rotor micro aerial vehicles and on a human-carried, shoulder-mounted harness. We show results of field experiments conducted in collaboration with growers and agronomists in vineyards, apple orchards and orange groves.