Uploaded July 2015 | Updated September 2026, 1 week ago
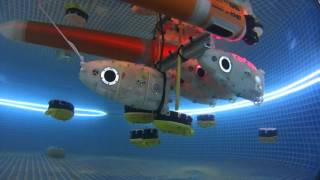
The Year of CoCoRo 30a/52: In CoCoRo the search for a sunken metallic object on the ground of the waterbody was dealt with in several scenarios. The most complex one was scenario #1 which consists of the following phases: (1) The base station at the water surface moves into the habitat with docked Jeff robots and a swarm of Lily robots confined to it. (2) The Jeff robots are released, sink to the ground and search the habitat. (3) As soon as the first Jeff robot has found the target it recruits other Jeff robots to this place by blue-light LED signals, leading to a positive feedback loop aggregating more and more Jeff robots at this place. (4) In the meanwhile the Lily robots swarm out, but not as a swarm, they rather build a chain that ultimately connects the surface station to the aggregation of Jeff robots on the ground. (5) Through this "relay chain" information (blink signals or other data) can be sent from the ground swarm to the surface station (and to human operators) and vice versa. This scenario #1 combines many of the individual algorithms and functionalities that were shown in the previous videos of "The Year of CoCoRo". This video is a computer animation illustrating the phases of our "scenario #1".
The Year of CoCoRo 30a/52: In CoCoRo the search for a sunken metallic object on the ground of the waterbody was dealt with in several scenarios. The most complex one was scenario #1 which consists of the following phases: (1) The base station at the water surface moves into the habitat with docked Jeff robots and a swarm of Lily robots confined to it. (2) The Jeff robots are released, sink to the ground and search the habitat. (3) As soon as the first Jeff robot has found the target it recruits other Jeff robots to this place by blue-light LED signals, leading to a positive feedback loop aggregating more and more Jeff robots at this place. (4) In the meanwhile the Lily robots swarm out, but not as a swarm, they rather build a chain that ultimately connects the surface station to the aggregation of Jeff robots on the ground. (5) Through this "relay chain" information (blink signals or other data) can be sent from the ground swarm to the surface station (and to human operators) and vice versa. This scenario #1 combines many of the individual algorithms and functionalities that were shown in the previous videos of "The Year of CoCoRo". This video is a computer animation illustrating the phases of our "scenario #1".