Uploaded July 2015 | Updated September 2026, 1 week ago
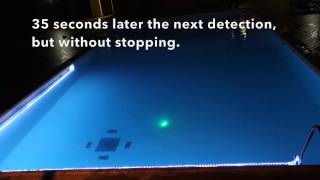
The Year of CoCoRo 27/52: After we tested our search algorithm for magnetic targets in the small pool (see previous movie from last week) we went out to a pool having several times this water volume. We used 4 Jeff robots this time, performing a random-walk based search program. Although we had many troubles in this long-night experiment we achieved some success in this extend search scenario. We had mostly software-problems that made the robots run too much along cyclic trajectories instead of doing an efficient random walk. This was the stuff we had to fight with in early summer 2014, later throughout the year we made significant improvements, as later videos will show. Although the target-finding rate was not perfect, the robots still found the target several times and it was the first time we operated our robots successfully at water depths below 2m.
The Year of CoCoRo 27/52: After we tested our search algorithm for magnetic targets in the small pool (see previous movie from last week) we went out to a pool having several times this water volume. We used 4 Jeff robots this time, performing a random-walk based search program. Although we had many troubles in this long-night experiment we achieved some success in this extend search scenario. We had mostly software-problems that made the robots run too much along cyclic trajectories instead of doing an efficient random walk. This was the stuff we had to fight with in early summer 2014, later throughout the year we made significant improvements, as later videos will show. Although the target-finding rate was not perfect, the robots still found the target several times and it was the first time we operated our robots successfully at water depths below 2m.