Uploaded March 2022 | Updated September 2026, 2 weeks ago
Cheap & Quick PCB, 3D Printing, CNC machining and fabrication services from PCBWay pcbway.com
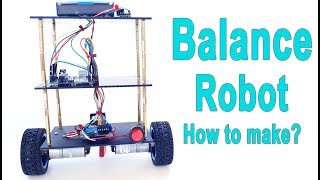
Generally, robot cars are built on a chassis with 2 DC motor wheels and a bovine wheel. While surfing the internet, I saw a 3D car design with a different structure, and I wanted to experience it by making it. As you can see the biggest difference compared to other robot cars is that it is built on 2 wheels. Of course, it is possible to make a slight wobble forward and backward from the balance point of view, but this did not hinder the robot's movements.
Also, a NodeMCU board with ESP8266 chip was used instead of an Arduino microcontroller. Thus, the robot was controlled via the internet. Hobby stepper motors were used instead of DC motors. Robot movements have become more balanced with use of stepper motors.
Since we are using ESP8266, it was necessary to move the robot wirelessly over WiFi, and a simple application was made for this.
Source code, Circuit diagram, PCB Gerber file, 3D STL file and App Inventor file:
▪️ pcbway.com/project/shareproject/Two_Wheel_Robot_ESP8266_WiFi_d878b6ab.html
▪️ instructables.com/ESP8266-Two-Wheel-Robot-NodeMCU-and-Stepper-Motor
▪️ hackster.io/mertarduino/esp8266-two-wheel-robot-nodemcu-and-stepper-motor-bdbee5
Install ESP8266 Add-on in Arduino IDE:
Enter arduino.esp8266.com/stable/package_esp8266com_index.json into the “Additional Boards Manager URLs”. Then, click the “OK” button.
MIT App Inventor:
Import the shared .aia extension resource file after logging in to https://appinventor.mit.edu/ . In this way, you can customize the application according to you.
Thanks for watching... Don't forget to subscribe for support!
Cheap & Quick PCB, 3D Printing, CNC machining and fabrication services from PCBWay pcbway.com
Generally, robot cars are built on a chassis with 2 DC motor wheels and a bovine wheel. While surfing the internet, I saw a 3D car design with a different structure, and I wanted to experience it by making it. As you can see the biggest difference compared to other robot cars is that it is built on 2 wheels. Of course, it is possible to make a slight wobble forward and backward from the balance point of view, but this did not hinder the robot's movements.
Also, a NodeMCU board with ESP8266 chip was used instead of an Arduino microcontroller. Thus, the robot was controlled via the internet. Hobby stepper motors were used instead of DC motors. Robot movements have become more balanced with use of stepper motors.
Since we are using ESP8266, it was necessary to move the robot wirelessly over WiFi, and a simple application was made for this.
Source code, Circuit diagram, PCB Gerber file, 3D STL file and App Inventor file:
▪️ pcbway.com/project/shareproject/Two_Wheel_Robot_ESP8266_WiFi_d878b6ab.html
▪️ instructables.com/ESP8266-Two-Wheel-Robot-NodeMCU-and-Stepper-Motor
▪️ hackster.io/mertarduino/esp8266-two-wheel-robot-nodemcu-and-stepper-motor-bdbee5
Install ESP8266 Add-on in Arduino IDE:
Enter arduino.esp8266.com/stable/package_esp8266com_index.json into the “Additional Boards Manager URLs”. Then, click the “OK” button.
MIT App Inventor:
Import the shared .aia extension resource file after logging in to https://appinventor.mit.edu/ . In this way, you can customize the application according to you.
Thanks for watching... Don't forget to subscribe for support!