Uploaded May 2011 | Updated September 2026, 42 minutes ago
I have been having problems "hitting the ceiling" on my motor capacity with the Protokopters, so I decided to do an off-copter test. In this test, the BL-Ctrl is run on PWM, rather than the normal I2C.
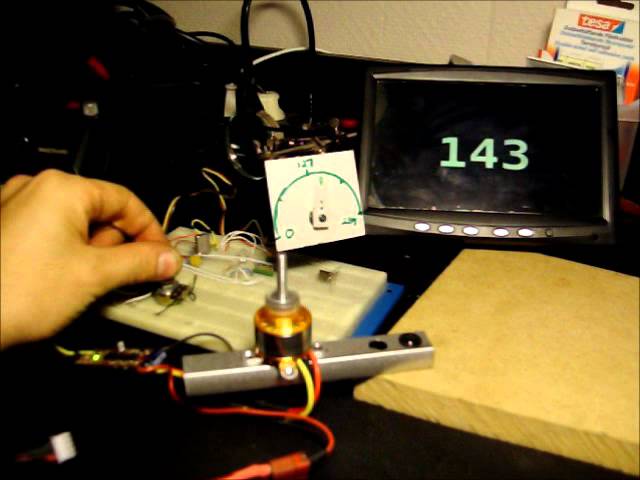
The rig is not as fancy as it may look ^_^ Control is provided by an Arduino running a slightly modified version of the "Knob" PWM demo. The "dial-indicator" is a standard RC servo connected to the same PWM signal as the BL-Ctrl. A 0-255 representation of the PWM value is sent via serial, to a simple perl-script that displays the value in a "font-bumped" terminal.
I also discovered in a test that I did not film, that when the current-limit has been in effect for a while, thermal protection causes the FETs to shut down, cutting power completely! This will explain part of a "dropping out of the sky" problem that I have been experiencing.
I have been having problems "hitting the ceiling" on my motor capacity with the Protokopters, so I decided to do an off-copter test. In this test, the BL-Ctrl is run on PWM, rather than the normal I2C.
The rig is not as fancy as it may look ^_^ Control is provided by an Arduino running a slightly modified version of the "Knob" PWM demo. The "dial-indicator" is a standard RC servo connected to the same PWM signal as the BL-Ctrl. A 0-255 representation of the PWM value is sent via serial, to a simple perl-script that displays the value in a "font-bumped" terminal.
I also discovered in a test that I did not film, that when the current-limit has been in effect for a while, thermal protection causes the FETs to shut down, cutting power completely! This will explain part of a "dropping out of the sky" problem that I have been experiencing.