Uploaded August 2025 | Updated September 2026, 3 weeks ago
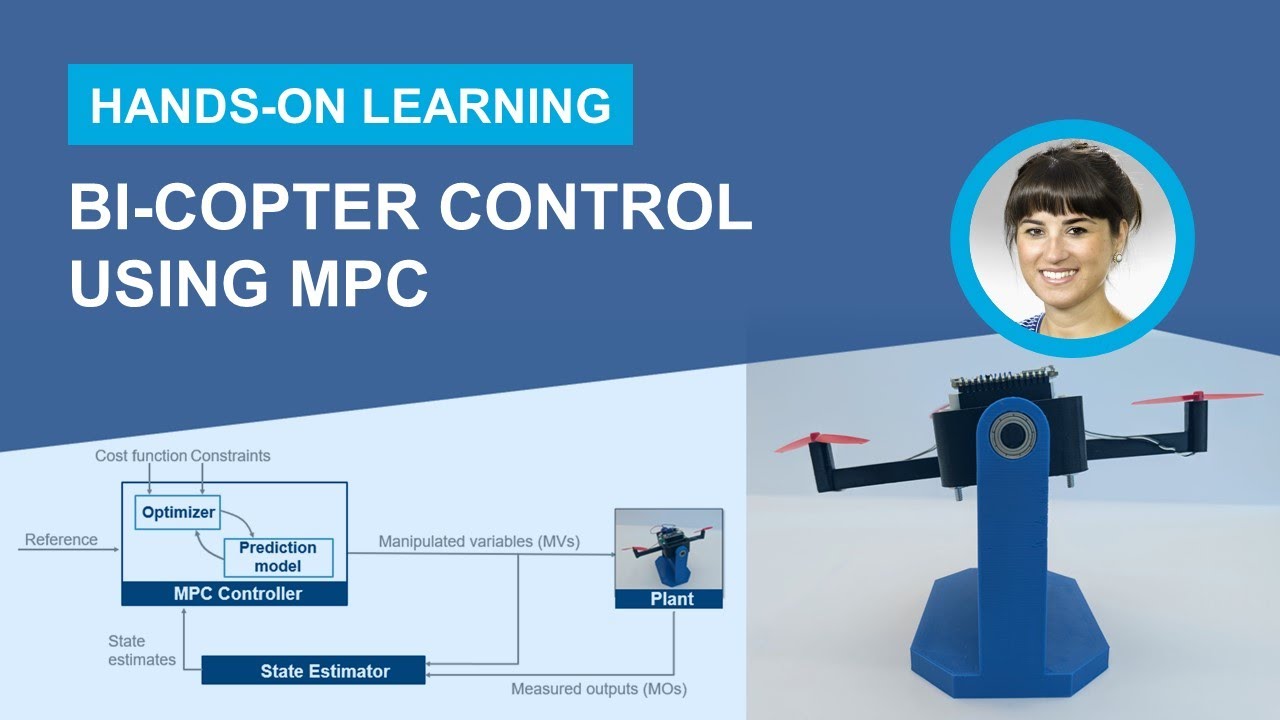
Gain hands-on experience in system identification and model predictive control (MPC) design using low-cost bi-copter hardware. Input-output data is collected through design of experiments, then used to identify a model of the bi-copter. This model is used as the prediction model in the design of MPC, which is deployed to bi-copter for angular position control.
Explore code and models used in this video: bit.ly/4nH1764
Additional Resources:
• Access Bi-Copter Materials bit.ly/4m70IJo
• Arduino Support from MATLAB and Simulink bit.ly/ArduinoSupport
Related Products:
• Model Predictive Control Toolbox bit.ly/MPC-Toolbox
• System Identification Toolbox bit.ly/System-Identification-Toolbox
Chapters:
00:00 Introduction
00:43 Bi-copter hardware overview
01:56 3D printing and assembly instructions
03:25 System identification and MPC design workflow
04:15 Step 1: Design of Experiments
09:40 Step 2: System identification
11:09 Step 3: MPC design
14:01 Step 4: Deployment and testing MPC in closed-loop
15:25 Testing controller with unmodeled disturbance
16:58 Summary
--------------------------------------------------------------------------------------------------------
Get a free product trial: goo.gl/ZHFb5u
Learn more about MATLAB: goo.gl/8QV7ZZ
Learn more about Simulink: goo.gl/nqnbLe
See what's new in MATLAB and Simulink: goo.gl/pgGtod
© 2025 The MathWorks, Inc. MATLAB and Simulink are registered trademarks of The MathWorks, Inc.
See mathworks.com/trademarks for a list of additional trademarks. Other product or brand names may be trademarks or registered trademarks of their respective holders.
Gain hands-on experience in system identification and model predictive control (MPC) design using low-cost bi-copter hardware. Input-output data is collected through design of experiments, then used to identify a model of the bi-copter. This model is used as the prediction model in the design of MPC, which is deployed to bi-copter for angular position control.
Explore code and models used in this video: bit.ly/4nH1764
Additional Resources:
• Access Bi-Copter Materials bit.ly/4m70IJo
• Arduino Support from MATLAB and Simulink bit.ly/ArduinoSupport
Related Products:
• Model Predictive Control Toolbox bit.ly/MPC-Toolbox
• System Identification Toolbox bit.ly/System-Identification-Toolbox
Chapters:
00:00 Introduction
00:43 Bi-copter hardware overview
01:56 3D printing and assembly instructions
03:25 System identification and MPC design workflow
04:15 Step 1: Design of Experiments
09:40 Step 2: System identification
11:09 Step 3: MPC design
14:01 Step 4: Deployment and testing MPC in closed-loop
15:25 Testing controller with unmodeled disturbance
16:58 Summary
--------------------------------------------------------------------------------------------------------
Get a free product trial: goo.gl/ZHFb5u
Learn more about MATLAB: goo.gl/8QV7ZZ
Learn more about Simulink: goo.gl/nqnbLe
See what's new in MATLAB and Simulink: goo.gl/pgGtod
© 2025 The MathWorks, Inc. MATLAB and Simulink are registered trademarks of The MathWorks, Inc.
See mathworks.com/trademarks for a list of additional trademarks. Other product or brand names may be trademarks or registered trademarks of their respective holders.