Uploaded June 2017 | Updated September 2026, 18 minutes ago
Actin enables surgical robotic control and surgical robotic assistant control all with real-time collision avoidance.
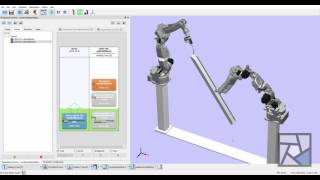
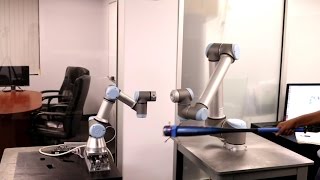
This video demonstrates Actin simulation and control for a surgical assistant (ABB YuMi robot with 14-DOF) unpacking a surgical tool.
The surgical assistant picks up a packaged surgical tool, cuts the packaging using a cutter, and removes the tool from the package. Actin's real-time collision avoidance algorithm is used to avoid collisions with the environment. The robot is programmed using Actin's visual programming tool called the Manipulation Director.
Follow the links below for more information on Actin's visual programming tool:
* outgoing.energid.info/documentation/actin/PAGE_ManipulationDirector.html
* energid.com/actin
Actin enables surgical robotic control and surgical robotic assistant control all with real-time collision avoidance.
This video demonstrates Actin simulation and control for a surgical assistant (ABB YuMi robot with 14-DOF) unpacking a surgical tool.
The surgical assistant picks up a packaged surgical tool, cuts the packaging using a cutter, and removes the tool from the package. Actin's real-time collision avoidance algorithm is used to avoid collisions with the environment. The robot is programmed using Actin's visual programming tool called the Manipulation Director.
Follow the links below for more information on Actin's visual programming tool:
* outgoing.energid.info/documentation/actin/PAGE_ManipulationDirector.html
* energid.com/actin