Uploaded March 2024 | Updated September 2026, 2 weeks ago
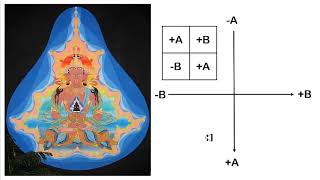
Here is a short video I made of the software I am working on that uses the 2x2 matrix version of Euler's formula to help solve the kinematics of the mechatronic arm that we are using in one of our medical devices. Each joint of the arm uses one 2x2 matrix to track the rotations:
[+cos(t) +sin(t)]
[-sin(t) +cos(t)]
This is really cool and I am very proud of my work.
Here is a short video I made of the software I am working on that uses the 2x2 matrix version of Euler's formula to help solve the kinematics of the mechatronic arm that we are using in one of our medical devices. Each joint of the arm uses one 2x2 matrix to track the rotations:
[+cos(t) +sin(t)]
[-sin(t) +cos(t)]
This is really cool and I am very proud of my work.