Uploaded March 2023 | Updated September 2026, 6 hours ago
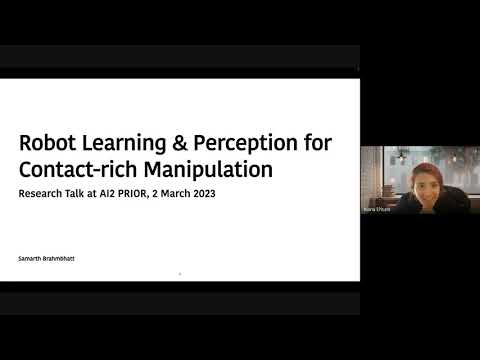
Abstract: Object rearrangement will become an important skill for collaborative robots as they increasingly operate in
unstructured environments. Rearrangement involves grasping, goal-conditioned navigation, and placement. In this talk, I will present our latest work, which focuses on placement. We learn a haptics-based RL policy in
simulation for inserting household objects into slots, and then transfer it to a real robot without fine-tuning or adaptation. I will also present some insights we gained along the way about which factors influence sim-
to-real transfer for such problems. Towards the end, I will also present previous computer vision work on perceiving hand-object contact, as
well as contact-correct image-based hand pose estimation. These algorithms can potentially enable utilization of Internet videos to provide manipulation demonstrations to collaborative robots.
Bio: Samarth Brahmbhatt is a research scientist at Intel Labs. Contact-rich manipulation is the common theme in his research work, which has spanned from learning haptics-based robotic object insertion, to hand-object
contact perception with thermal cameras. He is interested in state, action, and control representations that enable learning generalizable manipulation policies. Samarth was previously a postdoctoral researcher with
Vladlen Koltun at Intel Labs, and a PhD student with James Hays and Charlie Kemp at Georgia Tech. In his free time, Samarth enjoys hiking, history, and languages. https://samarth-robo.github.io.
Abstract: Object rearrangement will become an important skill for collaborative robots as they increasingly operate in
unstructured environments. Rearrangement involves grasping, goal-conditioned navigation, and placement. In this talk, I will present our latest work, which focuses on placement. We learn a haptics-based RL policy in
simulation for inserting household objects into slots, and then transfer it to a real robot without fine-tuning or adaptation. I will also present some insights we gained along the way about which factors influence sim-
to-real transfer for such problems. Towards the end, I will also present previous computer vision work on perceiving hand-object contact, as
well as contact-correct image-based hand pose estimation. These algorithms can potentially enable utilization of Internet videos to provide manipulation demonstrations to collaborative robots.
Bio: Samarth Brahmbhatt is a research scientist at Intel Labs. Contact-rich manipulation is the common theme in his research work, which has spanned from learning haptics-based robotic object insertion, to hand-object
contact perception with thermal cameras. He is interested in state, action, and control representations that enable learning generalizable manipulation policies. Samarth was previously a postdoctoral researcher with
Vladlen Koltun at Intel Labs, and a PhD student with James Hays and Charlie Kemp at Georgia Tech. In his free time, Samarth enjoys hiking, history, and languages. https://samarth-robo.github.io.