Uploaded April 2022 | Updated September 2026, 2 hours ago
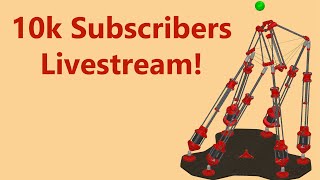
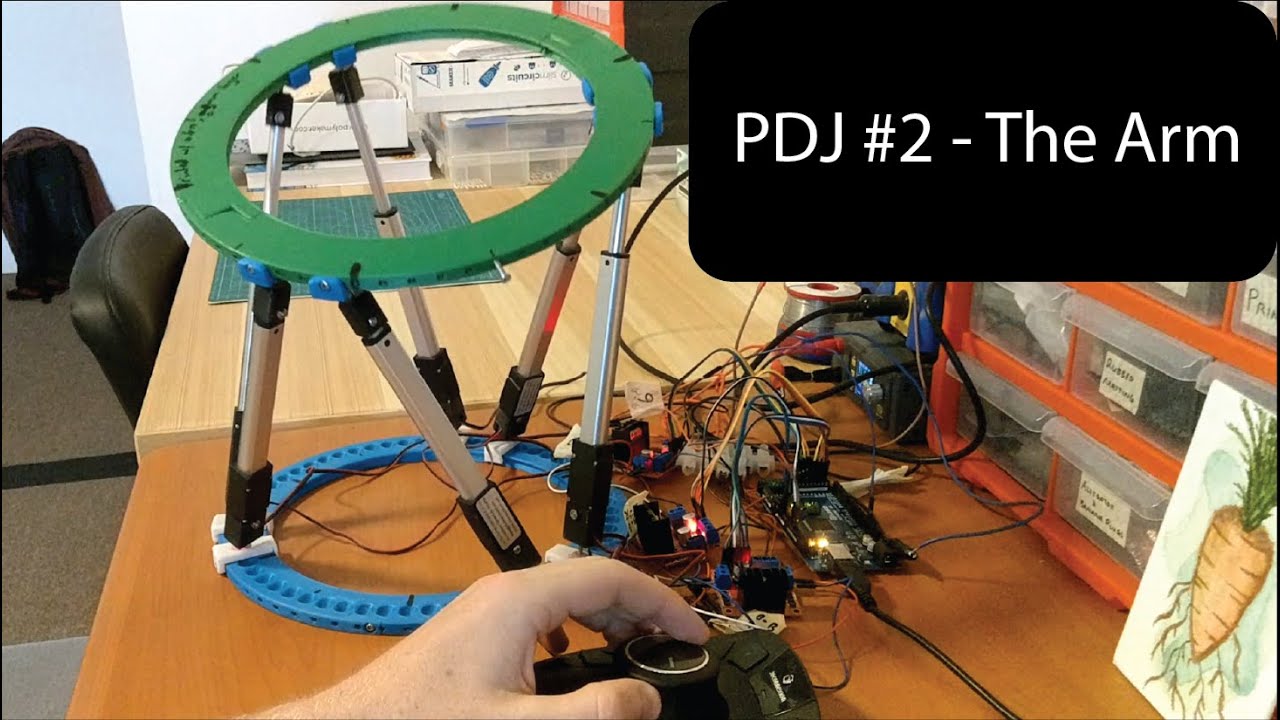
In this video I cover the current design for Jugglebot's arm - a 6 DOF parallel manipulator, commonly referred to as a Stewart Platform.
Link to Stewart Platform Wikipedia page:
en.wikipedia.org/wiki/Stewart_platform
00:00 Start
01:25 Serial vs. Parallel Robots
03:58 Why Jugglebot will use Parallel Robots
04:58 Stewart Platform Terminology
05:16 How This Design Works
07:46 How to Lay Out the Legs
08:56 Finding the Best Leg Layout
13:59 What Went Wrong with the Simulation?
17:49 How to Control a Stewart Platform
18:51 Final Thoughts