Uploaded February 2016 | Updated September 2026, 3 weeks ago
As the software project 2015 at leibniz university hannover we had the task to build a "game" where virtual an real robots find and collect regenerating ressources on a field with virtual walls.
They are not allowed to go through walls or be on the same field.
The program contains of a beamer application which will show a field on the ground, a main game server and gui to control everything and the real robots running the same AI as the virtual robots.
Someone even wrote an android app to control robots manually and a minecraft plugin to show the map in the game.
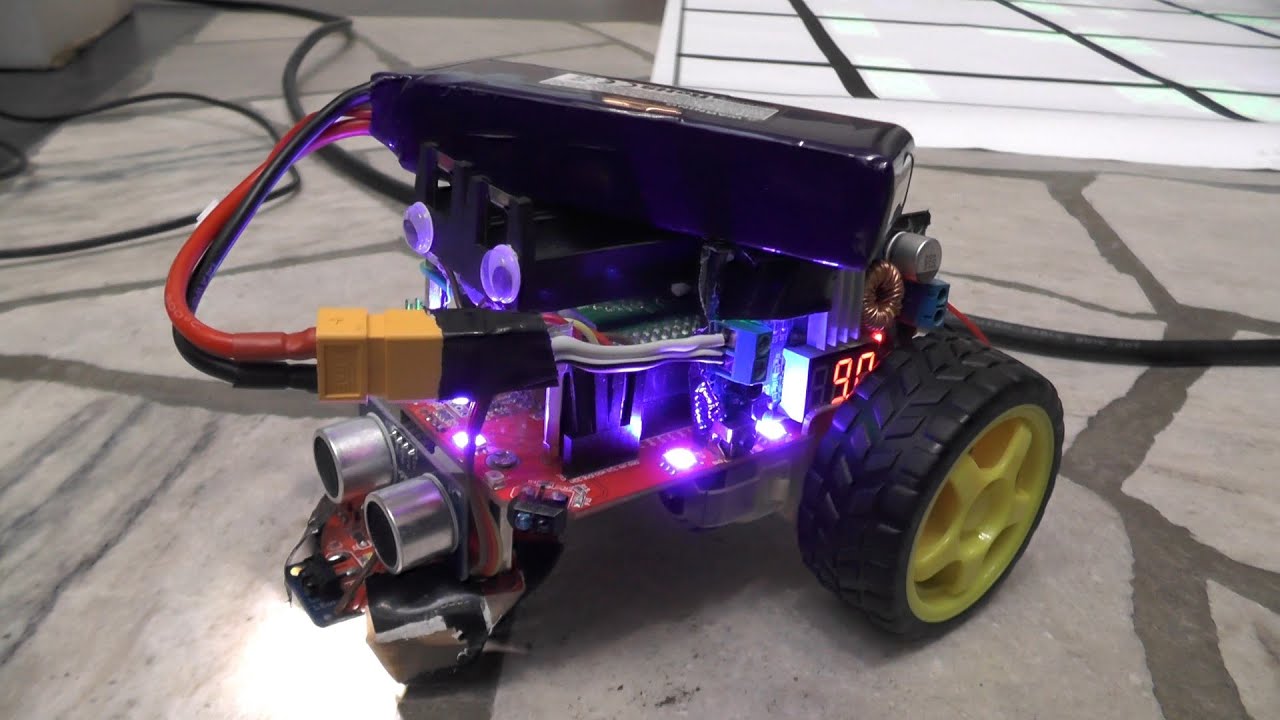
We used pi4j to access pins on the raspberry pi 2 and wrote classes to access all pi2go features directly from a java program as we had to use java for everything.
I changed the battery on the robot to a 3s LiPo and voltage converter to get a stable voltage of 9v.
The ultrasonic sensor was not in use.
A color sensor is also not in use but was planned and exists in the program.
Everything communicates with mqtt and it is possible to use visualizations, game servers and robots from other groups who had the same task and used a compatible protocol.
Links to videos from other participants with more information coming soon:
Group 2 Video: youtube.com/watch?v=JEvTibSQQw8
------------------------------------------
Project site from group 2: sightly-robot.de
You can support me on patreon: patreon.com/gigawipf