Uploaded May 2018 | Updated September 2026, 2 weeks ago
ICRA 2018 Spotlight Video
Interactive Session Thu PM Pod S.3
Authors: Mendivez Vasquez, Bruno Luis; Barca, Jan Carlo
Title: Network Topology Inference in Swarm Robotics
Abstract:
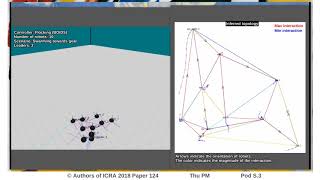
Swarm robotics refers to the implementation of swarm intelligence features like autonomy and self-organization to a collective of robots. This study focuses on the construction of a topological graph that represents both the magnitude and orientation of swarm interactions. Such structure is used for identifying global parameters like leadership and to derive a relationship between the distribution of interaction magnitudes and swarm parameters. Interaction magnitudes were derived from the trajectory distance between nearest neighbors and it was found that the distribution is able to differentiate between only a small subset of controllers, communication ranges and swarm sizes. Leader detection was based on the analysis of position vectors orientation in local neighborhoods. The method was successful at a 100% rate for 10 and 30 robots, while for 60 a minimum rate of 67% was obtained. Additionally, processing times never exceeded a simulation duration for swarms up to 30 robots, with the potential to parallelize for larger sizes.
ICRA 2018 Spotlight Video
Interactive Session Thu PM Pod S.3
Authors: Mendivez Vasquez, Bruno Luis; Barca, Jan Carlo
Title: Network Topology Inference in Swarm Robotics
Abstract:
Swarm robotics refers to the implementation of swarm intelligence features like autonomy and self-organization to a collective of robots. This study focuses on the construction of a topological graph that represents both the magnitude and orientation of swarm interactions. Such structure is used for identifying global parameters like leadership and to derive a relationship between the distribution of interaction magnitudes and swarm parameters. Interaction magnitudes were derived from the trajectory distance between nearest neighbors and it was found that the distribution is able to differentiate between only a small subset of controllers, communication ranges and swarm sizes. Leader detection was based on the analysis of position vectors orientation in local neighborhoods. The method was successful at a 100% rate for 10 and 30 robots, while for 60 a minimum rate of 67% was obtained. Additionally, processing times never exceeded a simulation duration for swarms up to 30 robots, with the potential to parallelize for larger sizes.