Uploaded May 2018 | Updated September 2026, 2 weeks ago
ICRA 2018 Spotlight Video
Interactive Session Thu AM Pod S.6
Authors: Guo, Meng; Andersson, Sofie; Dimarogonas, Dimos V.
Title: Human-In-The-Loop Mixed-Initiative Control under Temporal Tasks
Abstract:
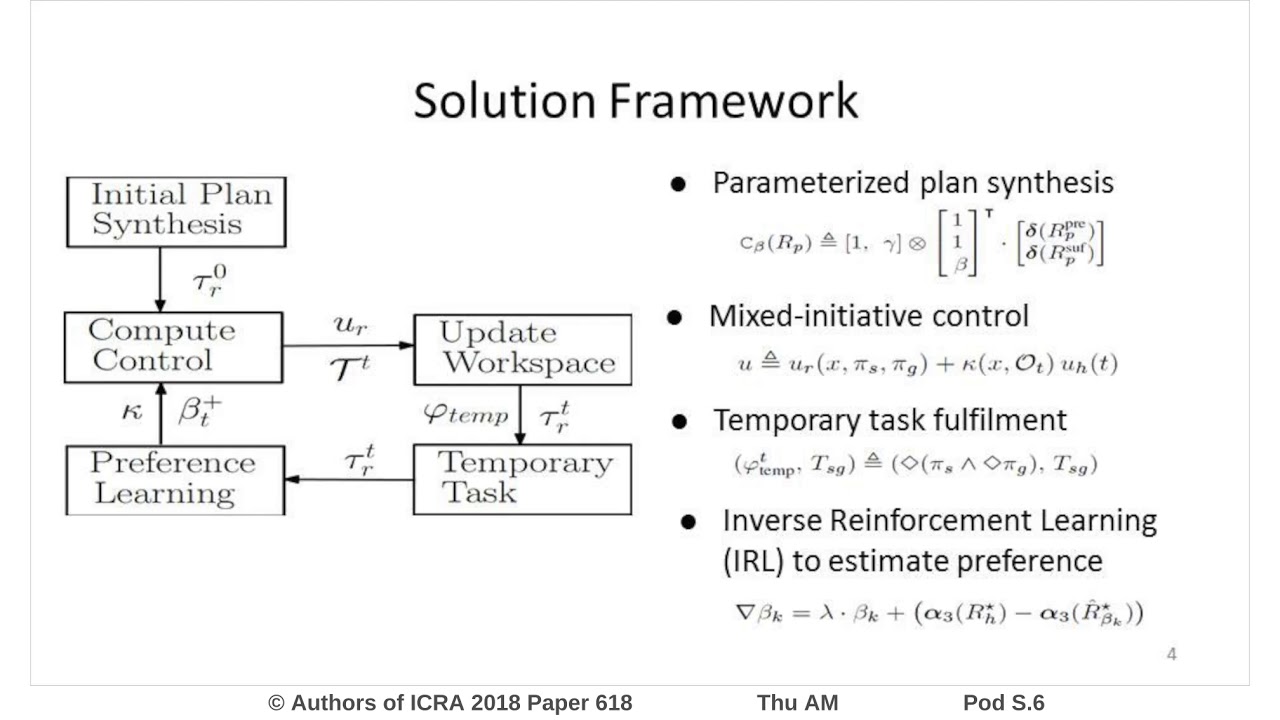
This paper considers the motion control and task planning problem of mobile robots under complex high-level tasks and human initiatives. The assigned task is specified as Linear Temporal Logic (LTL) formulas that consist of hard and soft constraints. The human initiative influences the robot autonomy in two explicit ways: with additive terms in the continuous controller and with contingent task assignments. We propose an online coordination scheme that encapsulates (i) a mixed-initiative continuous controller that ensures all-time safety despite of possible human errors, (ii) a plan adaptation scheme that accommodates new features discovered in the workspace and short-term tasks assigned by the operator during run time, and (iii) an iterative inverse reinforcement learning (IRL) algorithm that allows the robot to asymptotically learn the human preference on the parameters during the plan synthesis. The results are demonstrated by both realistic human-in-the-loop simulations and experiments.
ICRA 2018 Spotlight Video
Interactive Session Thu AM Pod S.6
Authors: Guo, Meng; Andersson, Sofie; Dimarogonas, Dimos V.
Title: Human-In-The-Loop Mixed-Initiative Control under Temporal Tasks
Abstract:
This paper considers the motion control and task planning problem of mobile robots under complex high-level tasks and human initiatives. The assigned task is specified as Linear Temporal Logic (LTL) formulas that consist of hard and soft constraints. The human initiative influences the robot autonomy in two explicit ways: with additive terms in the continuous controller and with contingent task assignments. We propose an online coordination scheme that encapsulates (i) a mixed-initiative continuous controller that ensures all-time safety despite of possible human errors, (ii) a plan adaptation scheme that accommodates new features discovered in the workspace and short-term tasks assigned by the operator during run time, and (iii) an iterative inverse reinforcement learning (IRL) algorithm that allows the robot to asymptotically learn the human preference on the parameters during the plan synthesis. The results are demonstrated by both realistic human-in-the-loop simulations and experiments.