Uploaded April 2023 | Updated September 2026, 11 hours ago
Microsoft Future Leaders in Robotics and AI Seminar Series: Interacting with the Environment for Autonomous Aerial Manipulation
Online Seminar
Junyi Geng
Assistant Professor
Pennsylvania State University
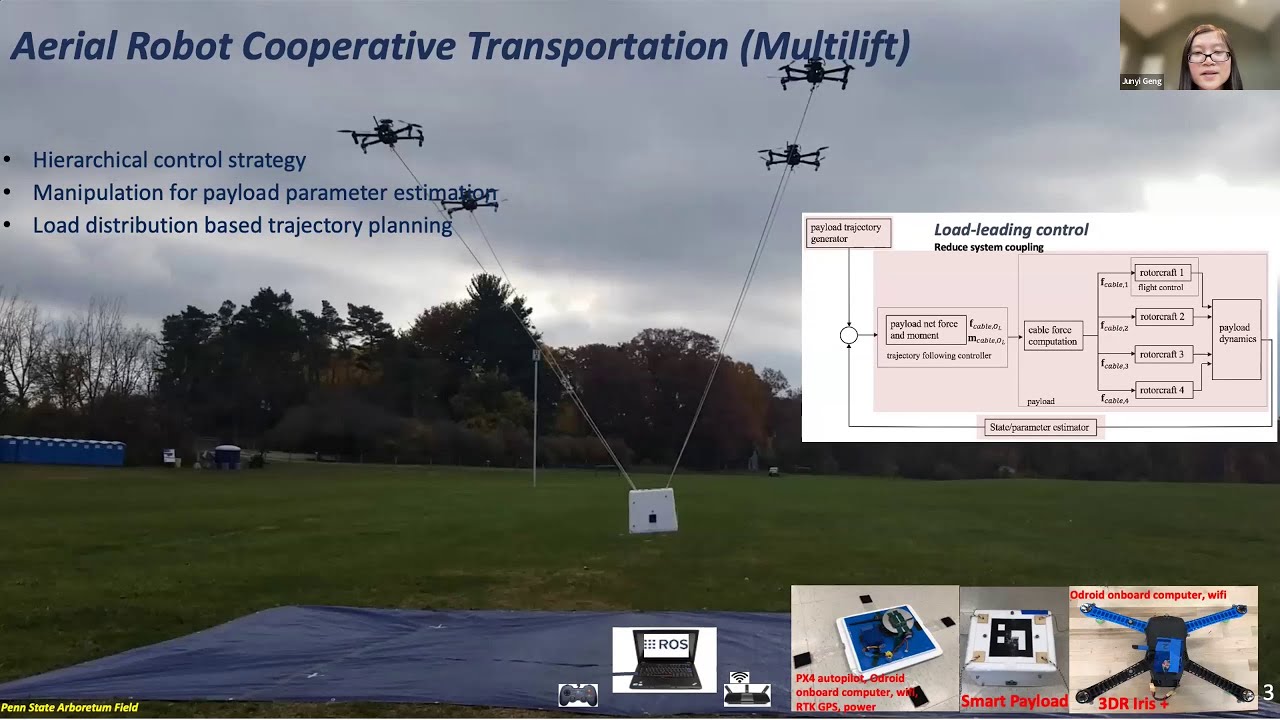
Today there are many tasks at high altitude that are still manually performed, which are expensive, inefficient, and hazardous to human life. The rapid growth of autonomous Uncrewed Aerial Vehicles (UAVs) has the potential to provide a safer and more efficient solution. Although the use of UAVs has grown rapidly, most of today’s vehicles still focus on passive tasks like inspection, surveillance, monitoring, remote sensing, etc. Aerial manipulation is intended to perform manipulation tasks, such as grasping, transporting, positioning, assembly, and disassembly of mechanical parts, etc., which can assist humans in performing tasks at high altitudes, or in hazardous situations. Aerial manipulation tasks require the robot to interact with the environment: perceive the environment, then perform the manipulation. When interacting with the environment, the key challenges are how to extract the useful information efficiently from the environment and better serve for accurate control. This talk will address these challenges for several manipulation tasks, including cooperative slung loadtransportation by multiple aerial robots, aerial bridge painting, general robotic manipulation, etc.
For more information on the Maryland Robotics Center see:
https://robotics.umd.edu
Microsoft Future Leaders in Robotics and AI Seminar Series: Interacting with the Environment for Autonomous Aerial Manipulation
Online Seminar
Junyi Geng
Assistant Professor
Pennsylvania State University
Today there are many tasks at high altitude that are still manually performed, which are expensive, inefficient, and hazardous to human life. The rapid growth of autonomous Uncrewed Aerial Vehicles (UAVs) has the potential to provide a safer and more efficient solution. Although the use of UAVs has grown rapidly, most of today’s vehicles still focus on passive tasks like inspection, surveillance, monitoring, remote sensing, etc. Aerial manipulation is intended to perform manipulation tasks, such as grasping, transporting, positioning, assembly, and disassembly of mechanical parts, etc., which can assist humans in performing tasks at high altitudes, or in hazardous situations. Aerial manipulation tasks require the robot to interact with the environment: perceive the environment, then perform the manipulation. When interacting with the environment, the key challenges are how to extract the useful information efficiently from the environment and better serve for accurate control. This talk will address these challenges for several manipulation tasks, including cooperative slung loadtransportation by multiple aerial robots, aerial bridge painting, general robotic manipulation, etc.
For more information on the Maryland Robotics Center see:
https://robotics.umd.edu