Uploaded March 2024 | Updated September 2026, 2 hours ago
Microsoft Future Leaders in Robotics and AI Seminar Series: What do smart robots dream of? Search-based decision-making in games, dynamical systems, and partially-observable environments
Online Seminar
Benjamin Riviere
PhD Candidate
California Institute of Technology
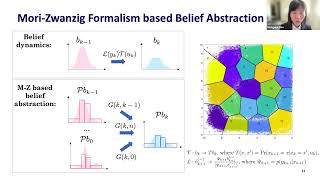
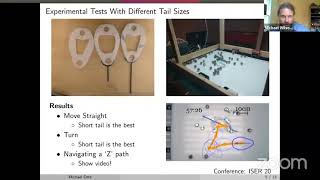
What do smart robots dream of? My research seeks answers to this question by designing how robots simulate the effect of their actions on the future, and how they use that information to make intelligent decisions. My work spans theory, algorithm design, and experiments. In this talk, I will develop this concept on three examples: (i) a large-scale game of tag where robots “juke” their opponents, (ii) a partially-observable setting where a spacecraft with faulty components must simultaneously excite useful observations to diagnoses its state and maintain safety, and (iii) a dynamical planning problem where a quadrotor navigates a windy arena to visit a collection of targets. All of these algorithms run in real-time and, rather than prescribing a particular solution, rely on the robot's ability to explore and execute intelligent behavior.
For more information on the Maryland Robotics Center see:
https://robotics.umd.edu
Microsoft Future Leaders in Robotics and AI Seminar Series: What do smart robots dream of? Search-based decision-making in games, dynamical systems, and partially-observable environments
Online Seminar
Benjamin Riviere
PhD Candidate
California Institute of Technology
What do smart robots dream of? My research seeks answers to this question by designing how robots simulate the effect of their actions on the future, and how they use that information to make intelligent decisions. My work spans theory, algorithm design, and experiments. In this talk, I will develop this concept on three examples: (i) a large-scale game of tag where robots “juke” their opponents, (ii) a partially-observable setting where a spacecraft with faulty components must simultaneously excite useful observations to diagnoses its state and maintain safety, and (iii) a dynamical planning problem where a quadrotor navigates a windy arena to visit a collection of targets. All of these algorithms run in real-time and, rather than prescribing a particular solution, rely on the robot's ability to explore and execute intelligent behavior.
For more information on the Maryland Robotics Center see:
https://robotics.umd.edu