Uploaded March 2023 | Updated September 2026, 1 hour ago
Microsoft Future Leaders in Robotics and AI Seminar Series: Assured Abstraction for Robotic Hierarchical Planning
Online Seminar
Mengxue Hou
Postdoctoral Fellow
Purdue University
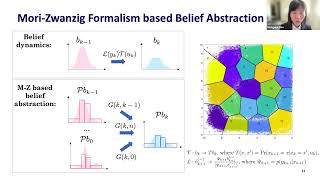
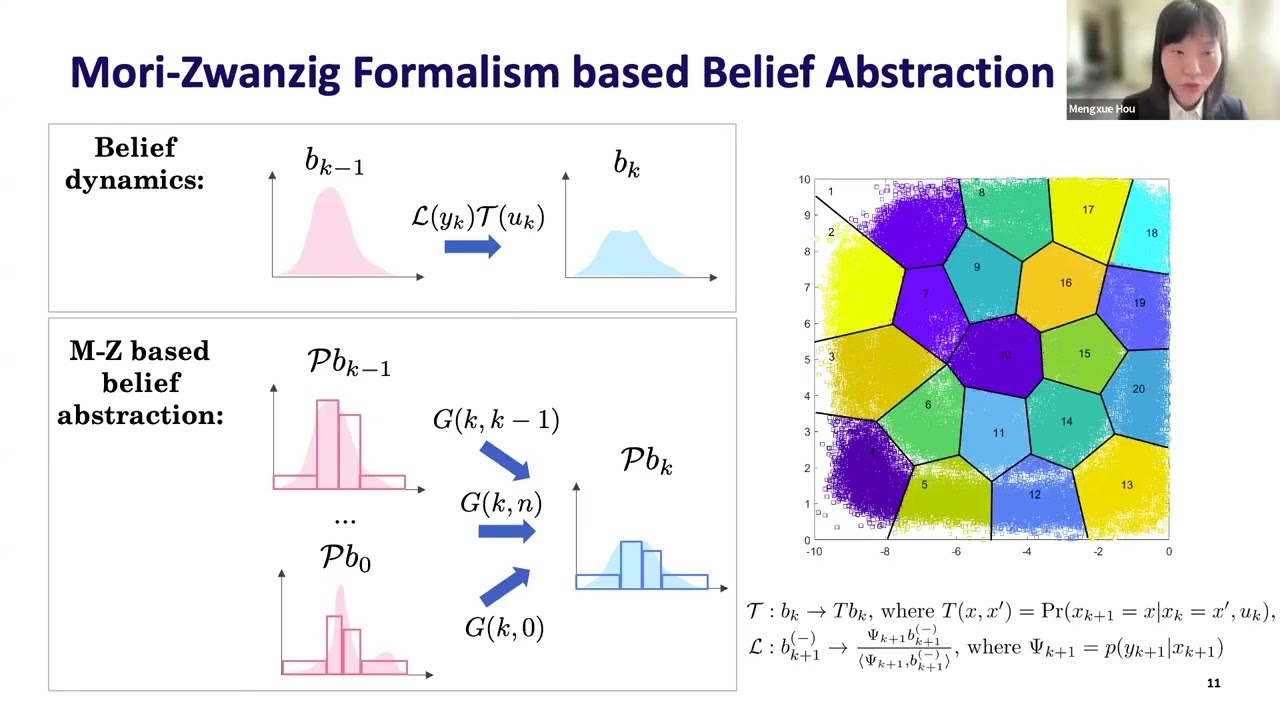
To enable a smart and autonomous system to be cognizant, taskable, and adaptive in exploring an unknown and unstructured environment, robotic decision-making relies on learning a parameterized knowledge representation. However, one fundamental challenge in deriving the parameterized representation is the undesirable trade-off between computation efficiency and model fidelity. This talk addresses this challenge in the context of underwater vehicle navigation in unknown marine environments. To improve fidelity of the reduced-order model, we develop a learning method to generate a non-Markovian reduced-order representation of the environmental dynamics. By incorporating the Mori-Zwanzig formalism, we prove that the proposed learning-based abstraction achieves a time-uniform model reduction error bound. Further, taking advantage of the abstracted model, we develop a novel hierarchical planning algorithm to generate the optimal multi-modal strategies with low computation cost.
For more information on the Maryland Robotics Center see:
https://robotics.umd.edu
Microsoft Future Leaders in Robotics and AI Seminar Series: Assured Abstraction for Robotic Hierarchical Planning
Online Seminar
Mengxue Hou
Postdoctoral Fellow
Purdue University
To enable a smart and autonomous system to be cognizant, taskable, and adaptive in exploring an unknown and unstructured environment, robotic decision-making relies on learning a parameterized knowledge representation. However, one fundamental challenge in deriving the parameterized representation is the undesirable trade-off between computation efficiency and model fidelity. This talk addresses this challenge in the context of underwater vehicle navigation in unknown marine environments. To improve fidelity of the reduced-order model, we develop a learning method to generate a non-Markovian reduced-order representation of the environmental dynamics. By incorporating the Mori-Zwanzig formalism, we prove that the proposed learning-based abstraction achieves a time-uniform model reduction error bound. Further, taking advantage of the abstracted model, we develop a novel hierarchical planning algorithm to generate the optimal multi-modal strategies with low computation cost.
For more information on the Maryland Robotics Center see:
https://robotics.umd.edu