Uploaded March 2023 | Updated September 2026, 11 hours ago
Microsoft Future Leaders in Robotics and AI Seminar Series: Agent-Environment Interactions for Uncertainty Reduction & Communication
Online Seminar
Alexandra Nilles
Postdoc Fellow
Cornell University
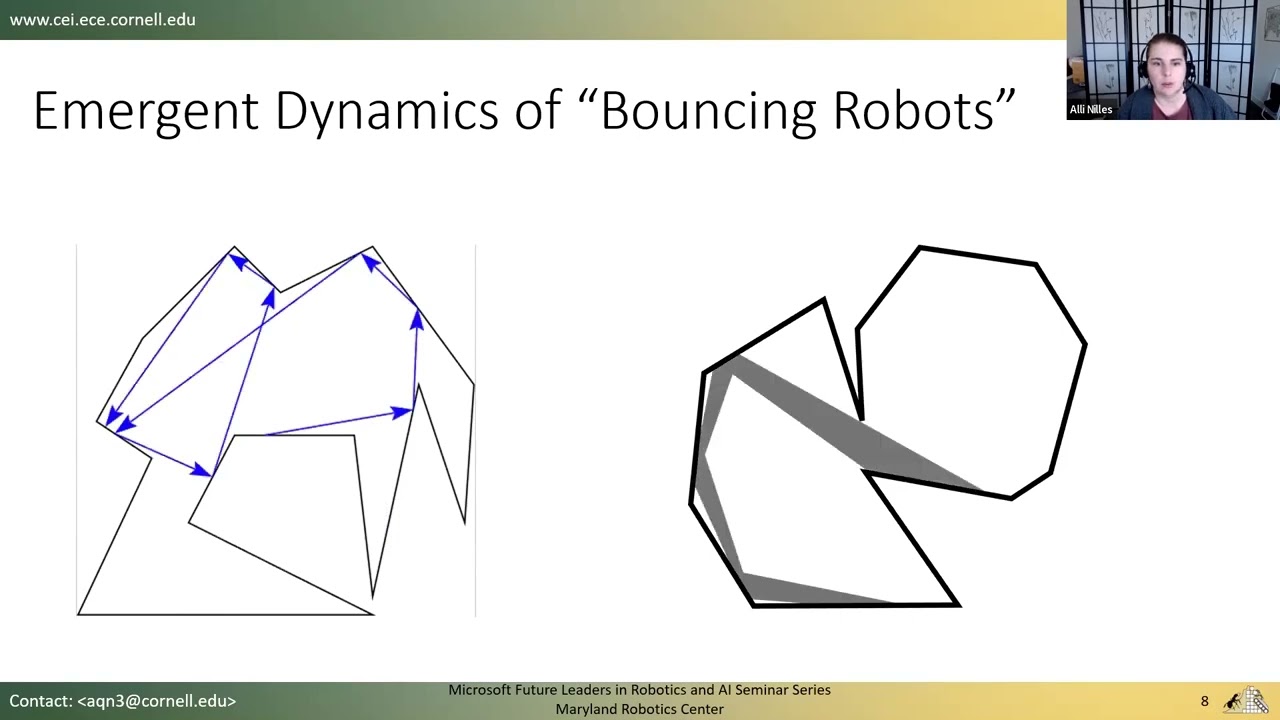
Most motion planning research focuses on collision avoidance, but it turns out that if robots are capable of making direct contact with boundaries of their environment, we can make our robotic systems more robust and less research-intensive. This talk will give highlights of the robustness results in "collision-inclusive motion planning," as well as extensions to multi-agent systems, manipulation of the environment, and possible applications in bio-inspired environmental monitoring.
For more information on the Maryland Robotics Center see:
https://robotics.umd.edu
Microsoft Future Leaders in Robotics and AI Seminar Series: Agent-Environment Interactions for Uncertainty Reduction & Communication
Online Seminar
Alexandra Nilles
Postdoc Fellow
Cornell University
Most motion planning research focuses on collision avoidance, but it turns out that if robots are capable of making direct contact with boundaries of their environment, we can make our robotic systems more robust and less research-intensive. This talk will give highlights of the robustness results in "collision-inclusive motion planning," as well as extensions to multi-agent systems, manipulation of the environment, and possible applications in bio-inspired environmental monitoring.
For more information on the Maryland Robotics Center see:
https://robotics.umd.edu