Uploaded April 2024 | Updated September 2026, 2 hours ago
Microsoft Future Leaders in Robotics and AI Seminar Series: Robot Safety and Generalization in the Era of Foundation Models
Online Seminar
Anushri Dixit
Postdoctoral Fellow
Princeton University
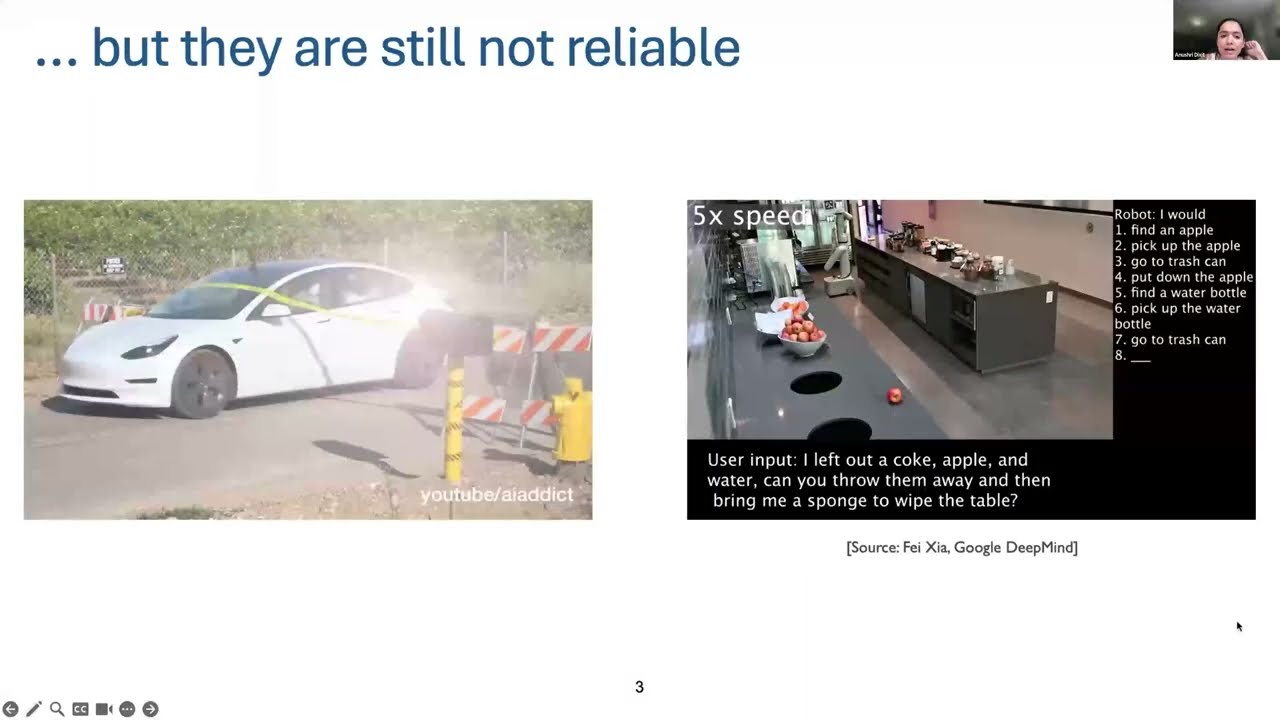
Significant strides in AI over the past few years have enabled robotic systems to interpret and interact with the world in increasingly versatile ways. The large, often multi-modal, datasets that are used to train modern learning-based systems endow robots with capabilities like scene understanding and commonsense reasoning. However, the safe integration and reliability of these learned models for robotics applications still remains in question. Learned perception systems fail to identify objects correctly and LLM-based planners hallucinate their outputs leading to unsafe robot behavior downstream. In this talk, I will discuss a technique called conformal prediction and its usefulness for quantifying the uncertainty of such learned models. First, I will discuss a framework for rigorously quantifying the uncertainty of a pre-trained obstacle detection system in a way that provides a formal assurance on correctness and safety for planning applications. Next, I will present a LLM-based planning framework wherein given a human instruction, the robot is statistically guaranteed to complete the task while asking for human help if it is uncertain. I will provide the experimental validation of these methods on various robotic platforms for navigation and mobile manipulation tasks.
For more information on the Maryland Robotics Center see:
https://robotics.umd.edu
Microsoft Future Leaders in Robotics and AI Seminar Series: Robot Safety and Generalization in the Era of Foundation Models
Online Seminar
Anushri Dixit
Postdoctoral Fellow
Princeton University
Significant strides in AI over the past few years have enabled robotic systems to interpret and interact with the world in increasingly versatile ways. The large, often multi-modal, datasets that are used to train modern learning-based systems endow robots with capabilities like scene understanding and commonsense reasoning. However, the safe integration and reliability of these learned models for robotics applications still remains in question. Learned perception systems fail to identify objects correctly and LLM-based planners hallucinate their outputs leading to unsafe robot behavior downstream. In this talk, I will discuss a technique called conformal prediction and its usefulness for quantifying the uncertainty of such learned models. First, I will discuss a framework for rigorously quantifying the uncertainty of a pre-trained obstacle detection system in a way that provides a formal assurance on correctness and safety for planning applications. Next, I will present a LLM-based planning framework wherein given a human instruction, the robot is statistically guaranteed to complete the task while asking for human help if it is uncertain. I will provide the experimental validation of these methods on various robotic platforms for navigation and mobile manipulation tasks.
For more information on the Maryland Robotics Center see:
https://robotics.umd.edu