Uploaded April 2023 | Updated September 2026, 25 minutes ago
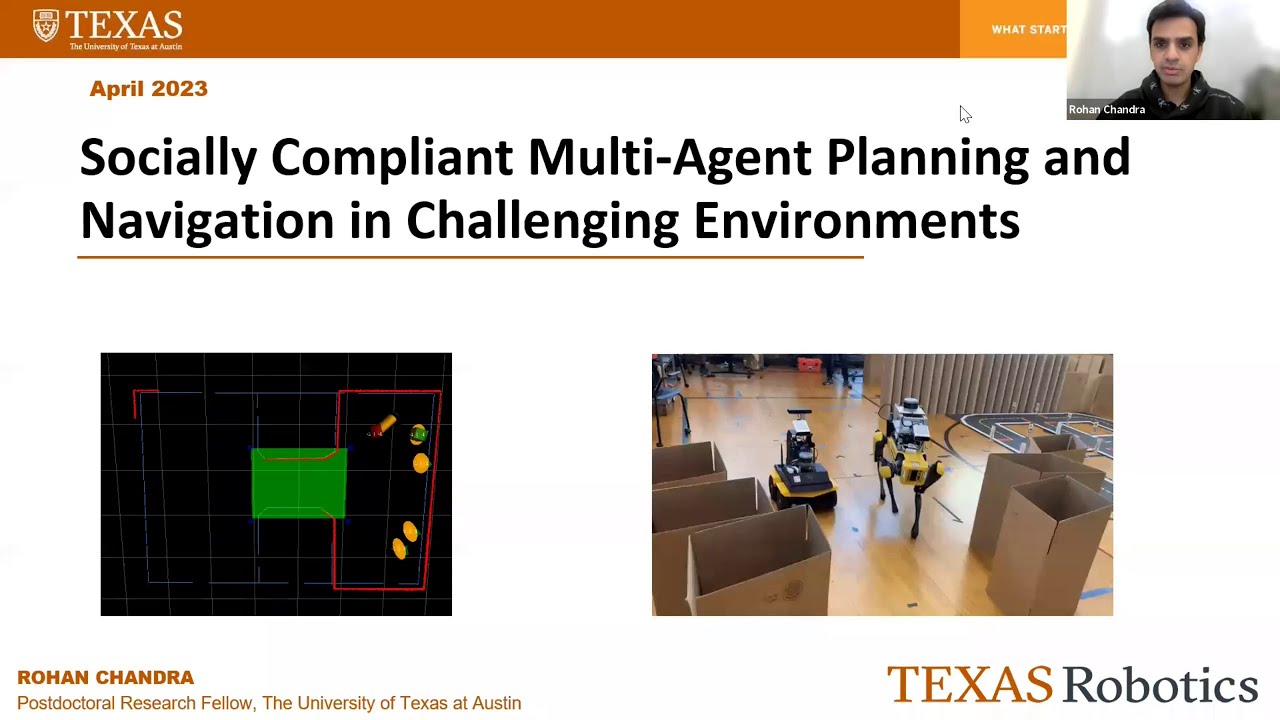
Microsoft Future Leaders in Robotics and AI Seminar Series: Socially Compliant Multi-Agent Planning and Navigation in Challenging Environments
Online Seminar
Rohan Chandra
Postdoctoral Fellow
University of Texas, Austin
Multi-agent social navigation is a complex problem in unstructured and challenging environments due to a myriad of factors such as limited observability, rough terrains, unpredictable non-cooperative agents, and so on. Research in multi-agent planning and navigation is spread across various domains such as perception, prediction, modeling, simulation, and planning in order to make multi-robot planning in such environments safer, efficient, and socially compliant in the presence of humans. In this talk, I will present a new framework for modeling socially compliant multi-agent planning and navigation in challenging environments. I will present results from experiments in autonomous driving and indoor social navigation that employ this framework. I will conclude by outlining a research vision that highlights open questions, presents opportunities for future work, and promotes diversity and inclusion, in this exciting and rapidly evolving field.
For more information on the Maryland Robotics Center see:
https://robotics.umd.edu
Microsoft Future Leaders in Robotics and AI Seminar Series: Socially Compliant Multi-Agent Planning and Navigation in Challenging Environments
Online Seminar
Rohan Chandra
Postdoctoral Fellow
University of Texas, Austin
Multi-agent social navigation is a complex problem in unstructured and challenging environments due to a myriad of factors such as limited observability, rough terrains, unpredictable non-cooperative agents, and so on. Research in multi-agent planning and navigation is spread across various domains such as perception, prediction, modeling, simulation, and planning in order to make multi-robot planning in such environments safer, efficient, and socially compliant in the presence of humans. In this talk, I will present a new framework for modeling socially compliant multi-agent planning and navigation in challenging environments. I will present results from experiments in autonomous driving and indoor social navigation that employ this framework. I will conclude by outlining a research vision that highlights open questions, presents opportunities for future work, and promotes diversity and inclusion, in this exciting and rapidly evolving field.
For more information on the Maryland Robotics Center see:
https://robotics.umd.edu