Uploaded May 2025 | Updated September 2026, 4 hours ago
Future Leaders in Robotics and AI Seminar Series: DiffTune: Auto-Tuning through Auto-Differentiation
Online Seminar
Sheng Cheng
Postdoctoral Fellow
University of Illinois Urbana Champaign
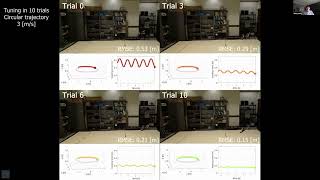
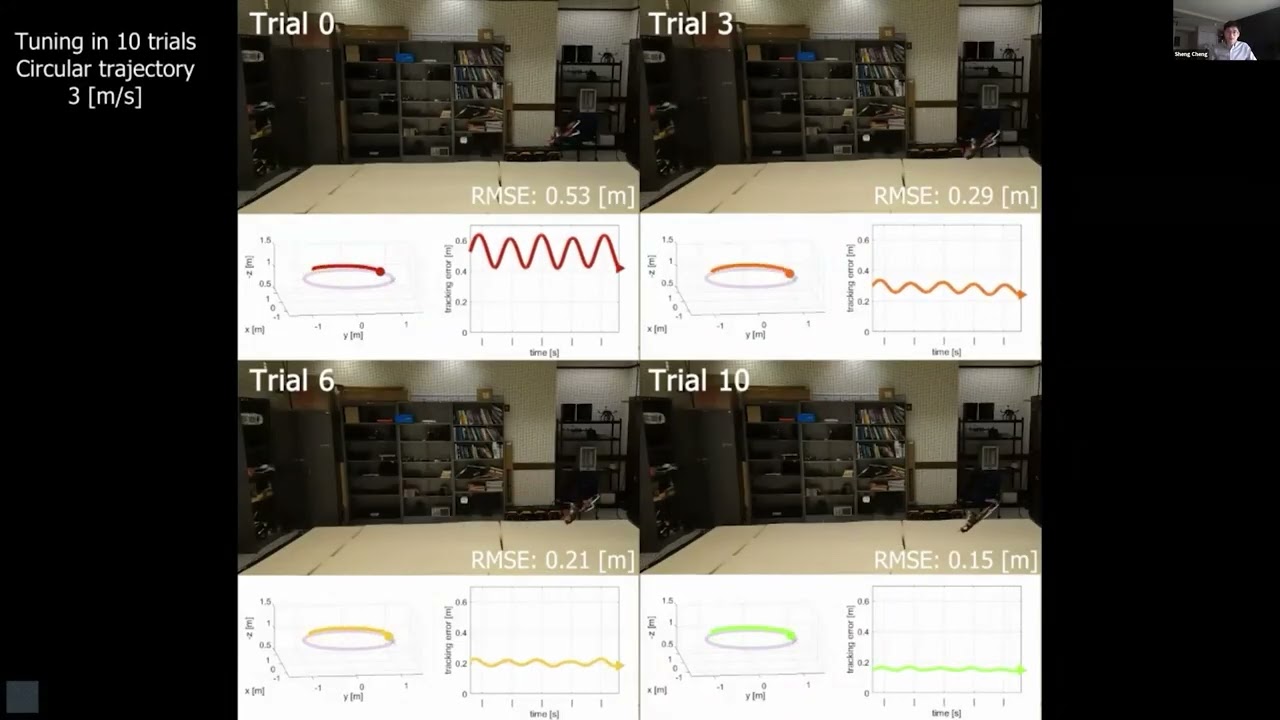
The performance of robots in high-level tasks is fundamentally tied to the quality of their low-level controllers, which often require fine-tuning. However, the nonlinear nature of robotic dynamics and controllers makes manual tuning a challenging and time-consuming process. In this talk, I will present our recent advances in controller auto-tuning leveraging auto-differentiation. I will also discuss the application of DiffTune to optimization-based controllers, such as model predictive control, highlighting its potential to streamline and enhance the tuning process.
For more information, please visit:
https://robotics.umd.edu/FutureLeaders
Future Leaders in Robotics and AI Seminar Series: DiffTune: Auto-Tuning through Auto-Differentiation
Online Seminar
Sheng Cheng
Postdoctoral Fellow
University of Illinois Urbana Champaign
The performance of robots in high-level tasks is fundamentally tied to the quality of their low-level controllers, which often require fine-tuning. However, the nonlinear nature of robotic dynamics and controllers makes manual tuning a challenging and time-consuming process. In this talk, I will present our recent advances in controller auto-tuning leveraging auto-differentiation. I will also discuss the application of DiffTune to optimization-based controllers, such as model predictive control, highlighting its potential to streamline and enhance the tuning process.
For more information, please visit:
https://robotics.umd.edu/FutureLeaders