Uploaded May 2025 | Updated September 2026, 6 hours ago
Future Leaders in Robotics and AI Seminar Series: Data Efficient Localization & Mapping for Distributed Multi-Robot Teams in the Field
Online Seminar
Yewei Huang
PhD Student
Stevens Institute of Technology
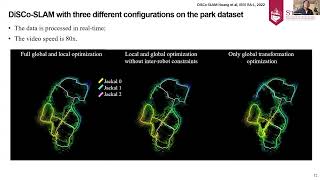
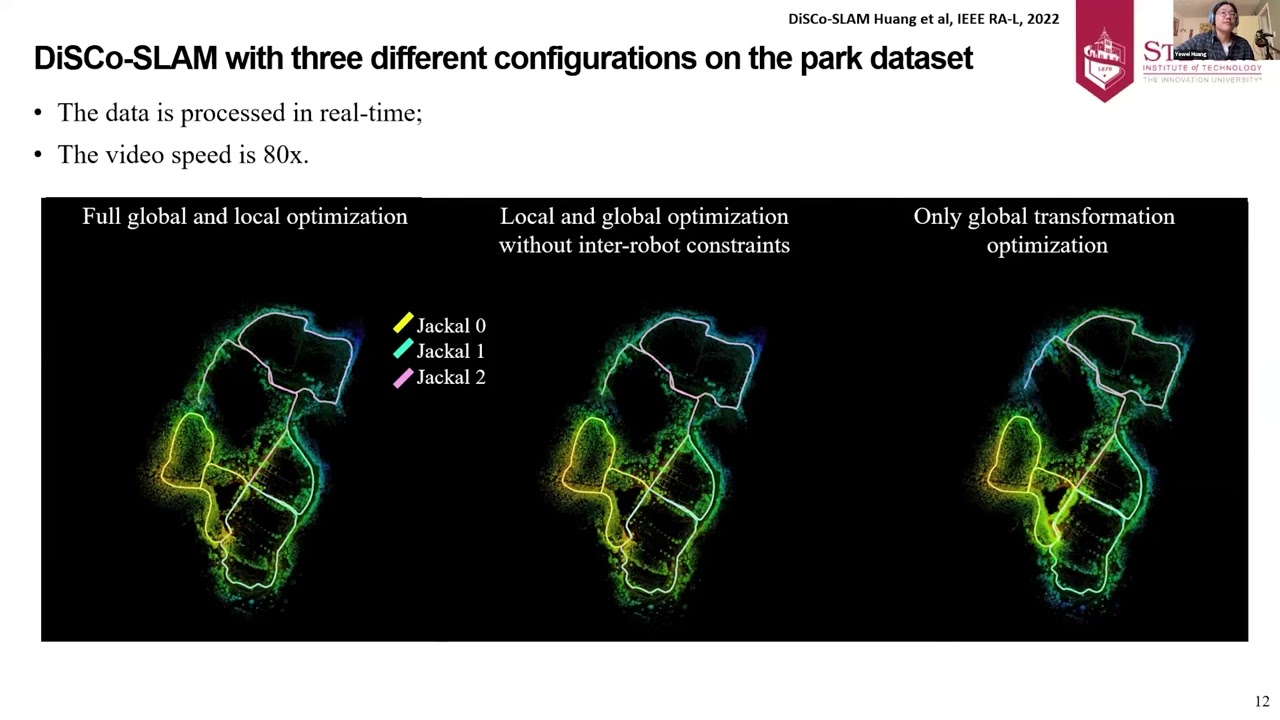
Multi-robot systems are capable of performing a wide range of time-sensitive tasks. Simultaneous Localization and Mapping (SLAM) is a critical capability that enables robots to execute these tasks effectively. However, communication bandwidth often becomes a limiting factor in many multi-robot scenarios, particularly when deploying robots in the field. In this talk, I will present how I enhance the data efficiency of multi-robot SLAM systems for both ground and marine vehicles, enabling multi-robot teams to explore the field collaboratively. I will present DiSCo-SLAM, a distributed multi-robot SLAM system that utilizes a compact LiDAR descriptor and a two-stage global and local optimization approach, designed to address the challenges of SLAM in GPS-denied environments. The system is then evolved to integrate with current developments in Large Language Models (LLMs), resulting in a graph-matching-based distributed multi-robot scene graph SLAM framework that works in both indoor and outdoor environments. Furthermore, the algorithm is extended to marine applications, supporting multi-robot teams equipped with sonar for collaborative exploration in oceanic environments.
For more information, please visit:
https://robotics.umd.edu/FutureLeaders
Future Leaders in Robotics and AI Seminar Series: Data Efficient Localization & Mapping for Distributed Multi-Robot Teams in the Field
Online Seminar
Yewei Huang
PhD Student
Stevens Institute of Technology
Multi-robot systems are capable of performing a wide range of time-sensitive tasks. Simultaneous Localization and Mapping (SLAM) is a critical capability that enables robots to execute these tasks effectively. However, communication bandwidth often becomes a limiting factor in many multi-robot scenarios, particularly when deploying robots in the field. In this talk, I will present how I enhance the data efficiency of multi-robot SLAM systems for both ground and marine vehicles, enabling multi-robot teams to explore the field collaboratively. I will present DiSCo-SLAM, a distributed multi-robot SLAM system that utilizes a compact LiDAR descriptor and a two-stage global and local optimization approach, designed to address the challenges of SLAM in GPS-denied environments. The system is then evolved to integrate with current developments in Large Language Models (LLMs), resulting in a graph-matching-based distributed multi-robot scene graph SLAM framework that works in both indoor and outdoor environments. Furthermore, the algorithm is extended to marine applications, supporting multi-robot teams equipped with sonar for collaborative exploration in oceanic environments.
For more information, please visit:
https://robotics.umd.edu/FutureLeaders