Uploaded April 2023 | Updated September 2026, 6 hours ago
Microsoft Future Leaders in Robotics and AI Seminar Series: A Category Theoretic Approach to Planning in a Complex World
Online Seminar
Angeline Aguinaldo
PhD Student
Computer Science Department
University of Maryland, College Park
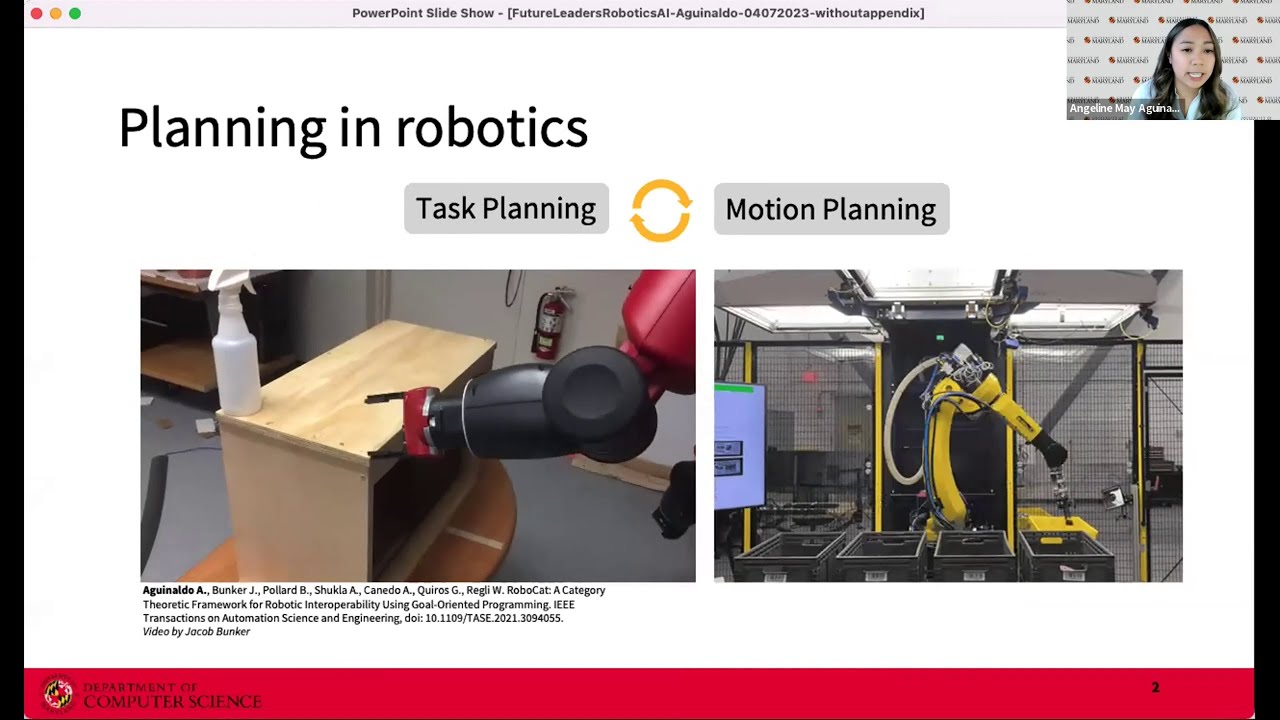
Context-aware autonomous agents possess the desirable ability to plan their tasks in spite of a dynamic and complex context. Structured representations of world states in the form of knowledge and scene graphs have shown to be useful tools for modeling such context information that are both intrinsic and extrinsic to the agent. Existing autonomous platforms, however, are limited in their ability to maintain and update world states represented in these languages during planning and execution in a principled manner. Additionally, existing classical procedures forgo the ability to implicitly preserve global semantics of the scene when local changes are induced or observed. This talk will discuss an alternate representation and framework for automated planning that uses functorial semantics from category theory and graph rewriting to gain such properties. We will also touch on how this representation might enable analogies in planning, online planning, and affordance-based reasoning as future work.
For more information on the Maryland Robotics Center see:
https://robotics.umd.edu
Microsoft Future Leaders in Robotics and AI Seminar Series: A Category Theoretic Approach to Planning in a Complex World
Online Seminar
Angeline Aguinaldo
PhD Student
Computer Science Department
University of Maryland, College Park
Context-aware autonomous agents possess the desirable ability to plan their tasks in spite of a dynamic and complex context. Structured representations of world states in the form of knowledge and scene graphs have shown to be useful tools for modeling such context information that are both intrinsic and extrinsic to the agent. Existing autonomous platforms, however, are limited in their ability to maintain and update world states represented in these languages during planning and execution in a principled manner. Additionally, existing classical procedures forgo the ability to implicitly preserve global semantics of the scene when local changes are induced or observed. This talk will discuss an alternate representation and framework for automated planning that uses functorial semantics from category theory and graph rewriting to gain such properties. We will also touch on how this representation might enable analogies in planning, online planning, and affordance-based reasoning as future work.
For more information on the Maryland Robotics Center see:
https://robotics.umd.edu