Uploaded May 2025 | Updated September 2026, 2 hours ago
Future Leaders in Robotics and AI Seminar Series: Who is Driving the Car? Modeling Driver Personas for Accurate Behavior Simulation in Autonomous Driving
Online Seminar
Laura Zheng
PhD Student
University of Maryland
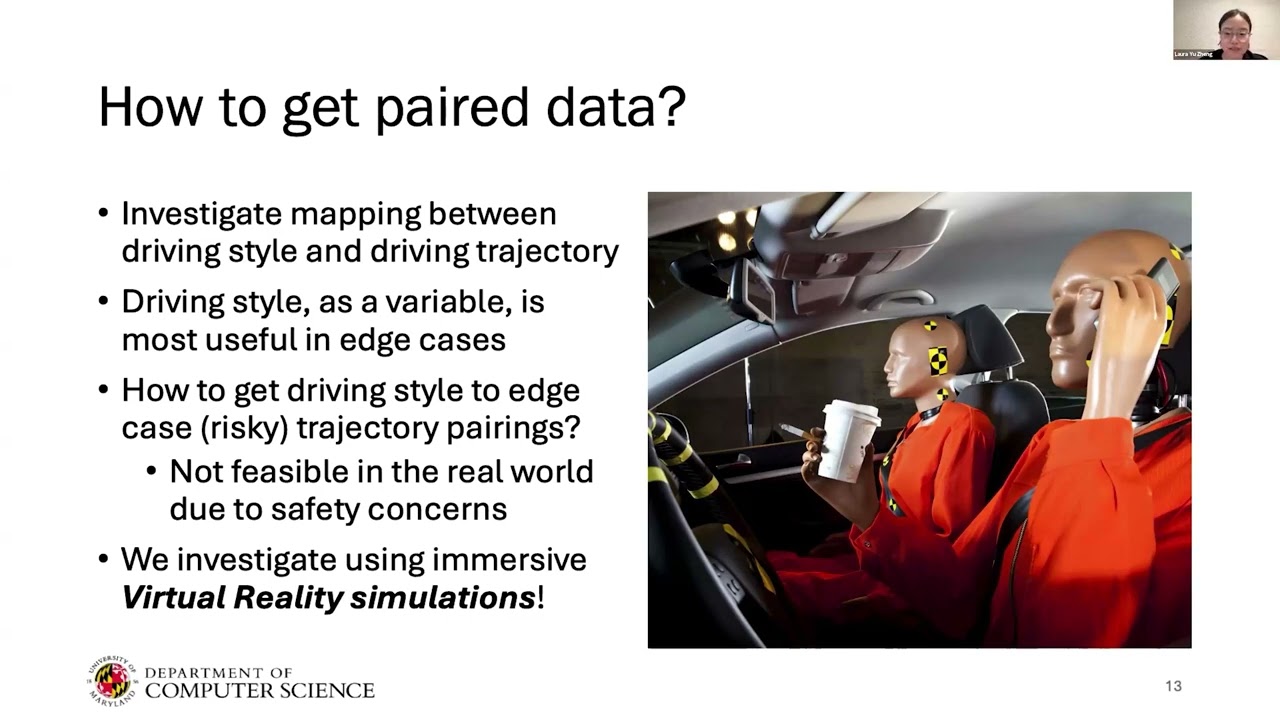
Human factors such as driving style are rarely explicitly modeled in traffic behavior simulation, yet they play an important role in describing the multi-modal decisions in trajectory forecasting. The primary reason for the lack of explicit modeling is due to the abstract notion of driving style, whose observations have yet to be explored with respect to trajectories. In this talk, I will present two novel approaches in quantification of observable driving style. The first approach is human-driven; we begin with querying humans directly, assessing both their self-reported driving style in addition to their evaluated driving style based on the Multi-Dimensional Driving Style Inventory, then correlating their assessed driving style with their driving behavior captured in an immersive virtual driving simulator, allowing for driving style classification of driving trajectories. The second approach is data-driven, where we explore driving style as a time-consistent latent variable that is independent of both scenario context and route intent. We model driving style using a library of LoRA modules, each of which finetunes the trajectory decoder to accommodate a particular driving style, resulting in diverse and controllable predictions of forecast trajectories with respect to individual driving style. These techniques make it easier for self-driving cars to navigate in a mixed autonomy of human-driven and automatically controlled vehicles in traffic.
For more information, please visit:
https://robotics.umd.edu/FutureLeaders
Future Leaders in Robotics and AI Seminar Series: Who is Driving the Car? Modeling Driver Personas for Accurate Behavior Simulation in Autonomous Driving
Online Seminar
Laura Zheng
PhD Student
University of Maryland
Human factors such as driving style are rarely explicitly modeled in traffic behavior simulation, yet they play an important role in describing the multi-modal decisions in trajectory forecasting. The primary reason for the lack of explicit modeling is due to the abstract notion of driving style, whose observations have yet to be explored with respect to trajectories. In this talk, I will present two novel approaches in quantification of observable driving style. The first approach is human-driven; we begin with querying humans directly, assessing both their self-reported driving style in addition to their evaluated driving style based on the Multi-Dimensional Driving Style Inventory, then correlating their assessed driving style with their driving behavior captured in an immersive virtual driving simulator, allowing for driving style classification of driving trajectories. The second approach is data-driven, where we explore driving style as a time-consistent latent variable that is independent of both scenario context and route intent. We model driving style using a library of LoRA modules, each of which finetunes the trajectory decoder to accommodate a particular driving style, resulting in diverse and controllable predictions of forecast trajectories with respect to individual driving style. These techniques make it easier for self-driving cars to navigate in a mixed autonomy of human-driven and automatically controlled vehicles in traffic.
For more information, please visit:
https://robotics.umd.edu/FutureLeaders