Uploaded April 2023 | Updated September 2026, 4 hours ago
Microsoft Future Leaders in Robotics and AI Seminar Series: Autonomous Ultrasound-Guided Robotics to Support Trauma Patients: From Diagnostics to Hemorrhage Control
Online Seminar
Lidia Al-Zogbi
PhD Candidate
Mechanical Engineering Department
Johns Hopkins University
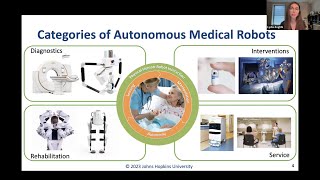
Trauma is among the leading causes of death in the United States with up to 29% of pre-hospital trauma deaths attributed to uncontrolled hemorrhages. Detecting life-threatening hemorrhages as soon as possible is crucial to increase patient survival chances, however invasive initial treatments en route to the hospital are often throttled when expert clinicians are a scarce resource, or are simply unavailable. In this talk, I will present how these shortcomings could be overcome by a user-independent autonomous robotic system I developed for initiating both diagnostics and interventional procedures to stabilize trauma patients. The robotic system can autonomously perform a standard ultrasound diagnostics exam, and offer critical support to first responders for initiating lifesaving hemorrhage control using intra-arterial balloon catheters. In particular, I will discuss the development process of a medical robotic system integrated with computer vision and medical imaging, autonomous ultrasound-guided robotic vascular access, and deep learning methods for predicting key intracorporeal anatomical landmarks.
For more information on the Maryland Robotics Center see:
https://robotics.umd.edu
Microsoft Future Leaders in Robotics and AI Seminar Series: Autonomous Ultrasound-Guided Robotics to Support Trauma Patients: From Diagnostics to Hemorrhage Control
Online Seminar
Lidia Al-Zogbi
PhD Candidate
Mechanical Engineering Department
Johns Hopkins University
Trauma is among the leading causes of death in the United States with up to 29% of pre-hospital trauma deaths attributed to uncontrolled hemorrhages. Detecting life-threatening hemorrhages as soon as possible is crucial to increase patient survival chances, however invasive initial treatments en route to the hospital are often throttled when expert clinicians are a scarce resource, or are simply unavailable. In this talk, I will present how these shortcomings could be overcome by a user-independent autonomous robotic system I developed for initiating both diagnostics and interventional procedures to stabilize trauma patients. The robotic system can autonomously perform a standard ultrasound diagnostics exam, and offer critical support to first responders for initiating lifesaving hemorrhage control using intra-arterial balloon catheters. In particular, I will discuss the development process of a medical robotic system integrated with computer vision and medical imaging, autonomous ultrasound-guided robotic vascular access, and deep learning methods for predicting key intracorporeal anatomical landmarks.
For more information on the Maryland Robotics Center see:
https://robotics.umd.edu