Uploaded July 2021 | Updated September 2026, 2 hours ago
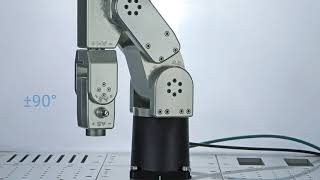
Users can now redefine the software limits of individual joints. The robot will not be able to move outside these limits, and will generate an error if it starts from a position outside of the specified limits. This feature can help to define a safe robot workspace for your applications. Cartesian range limits are still in development and will be released as part of a future firmware release.
Firmware 8.4 full features & benefits: mecademic.com/en/mecademic-robotics-releases-new-firmware-for-its-meca500-robot
---
About this robot: The Meca500 is the world's smallest, most precise and compact industrial robotic arm. To learn more: mecademic.com
Users can now redefine the software limits of individual joints. The robot will not be able to move outside these limits, and will generate an error if it starts from a position outside of the specified limits. This feature can help to define a safe robot workspace for your applications. Cartesian range limits are still in development and will be released as part of a future firmware release.
Firmware 8.4 full features & benefits: mecademic.com/en/mecademic-robotics-releases-new-firmware-for-its-meca500-robot
---
About this robot: The Meca500 is the world's smallest, most precise and compact industrial robotic arm. To learn more: mecademic.com