Uploaded April 2019 | Updated November 2026, 1 hour ago
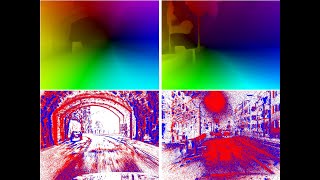
Event cameras are vision sensors that record asynchronous streams of per-pixel brightness changes, referred to as “events”. They have appealing advantages over frame-based cameras for computer vision, including high temporal resolution, high dynamic range, and no motion blur. Due to the sparse, non-uniform spatiotemporal layout of the event signal, pattern recognition algorithms typically aggregate events into a grid-based representation and subsequently process it by a standard vision pipeline, e.g., Convolutional Neural Network (CNN). In this work, we introduce a general framework to convert event streams into grid-based representations through a sequence of differentiable operations. Our framework comes with two main advantages: (i) allows learning the input event representation together with the task dedicated network in an end to end manner, and (ii) lays out a taxonomy that unifies the majority of extant event representations in the literature and identifies novel ones. Empirically, we show that our approach to learning the event representation end-to-end yields an improvement of approximately 12% on optical flow estimation and object recognition over state-of-the-art methods.
Reference:
D. Gehrig, A. Loquercio, K. G. Derpanis, D. Scaramuzza
End-to-End Learning of Representations for Asynchronous Event-Based Data
International Conference on Computer Vision, Seoul, Oct. 2019
PDF: http://rpg.ifi.uzh.ch/docs/ICCV19_Gehrig.pdf
Code: github.com/uzh-rpg/rpg_event_representation_learning
See also our research page on event based vision: http://rpg.ifi.uzh.ch/research_dvs.html
For event-camera datasets and event camera simulator, see here:
http://rpg.ifi.uzh.ch/davis_data.html
http://rpg.ifi.uzh.ch/esim/index.html
Other resources on event cameras (publications, software, drivers, where to buy, etc.):
github.com/uzh-rpg/event-based_vision_resources
Affiliations: D. Gehrig, A. Loquercio, and D. Scaramuzza are with the Robotics and Perception Group, Dept. of Informatics, University of Zurich, and Dept. of Neuroinformatics, University of Zurich and ETH Zurich, Switzerland http://rpg.ifi.uzh.ch/.
Konstantinos G. Derpanis is from Ryerson University (ryersonvisionlab.github.io/) and with the Samsung AI Centre in Toronto.
Event cameras are vision sensors that record asynchronous streams of per-pixel brightness changes, referred to as “events”. They have appealing advantages over frame-based cameras for computer vision, including high temporal resolution, high dynamic range, and no motion blur. Due to the sparse, non-uniform spatiotemporal layout of the event signal, pattern recognition algorithms typically aggregate events into a grid-based representation and subsequently process it by a standard vision pipeline, e.g., Convolutional Neural Network (CNN). In this work, we introduce a general framework to convert event streams into grid-based representations through a sequence of differentiable operations. Our framework comes with two main advantages: (i) allows learning the input event representation together with the task dedicated network in an end to end manner, and (ii) lays out a taxonomy that unifies the majority of extant event representations in the literature and identifies novel ones. Empirically, we show that our approach to learning the event representation end-to-end yields an improvement of approximately 12% on optical flow estimation and object recognition over state-of-the-art methods.
Reference:
D. Gehrig, A. Loquercio, K. G. Derpanis, D. Scaramuzza
End-to-End Learning of Representations for Asynchronous Event-Based Data
International Conference on Computer Vision, Seoul, Oct. 2019
PDF: http://rpg.ifi.uzh.ch/docs/ICCV19_Gehrig.pdf
Code: github.com/uzh-rpg/rpg_event_representation_learning
See also our research page on event based vision: http://rpg.ifi.uzh.ch/research_dvs.html
For event-camera datasets and event camera simulator, see here:
http://rpg.ifi.uzh.ch/davis_data.html
http://rpg.ifi.uzh.ch/esim/index.html
Other resources on event cameras (publications, software, drivers, where to buy, etc.):
github.com/uzh-rpg/event-based_vision_resources
Affiliations: D. Gehrig, A. Loquercio, and D. Scaramuzza are with the Robotics and Perception Group, Dept. of Informatics, University of Zurich, and Dept. of Neuroinformatics, University of Zurich and ETH Zurich, Switzerland http://rpg.ifi.uzh.ch/.
Konstantinos G. Derpanis is from Ryerson University (ryersonvisionlab.github.io/) and with the Samsung AI Centre in Toronto.