Uploaded April 2023 | Updated September 2026, 1 week ago
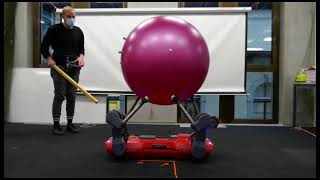
This video is part of the paper "Circus ANYmal: A Quadruped Learning Dexterous Manipulation with Its Limbs" by Fan Shi, Timon Homberger, Joonho Lee, Takahiro Miki, Moju Zhao, Farbod Farshidian, Kei Okada, Masayuki Inaba, Marco Hutter from JSK Lab, Department of Creative-Infomatics, The University of Tokyo, and Robotics Systems Lab, ETH Zurich
Presented at the 2021 IEEE International Conference on Robotics and Automation (ICRA)
See the full proceedings: ieeexplore.ieee.org/xpl/conhome/9560720/proceeding
#robot #robotics
This video is part of the paper "Circus ANYmal: A Quadruped Learning Dexterous Manipulation with Its Limbs" by Fan Shi, Timon Homberger, Joonho Lee, Takahiro Miki, Moju Zhao, Farbod Farshidian, Kei Okada, Masayuki Inaba, Marco Hutter from JSK Lab, Department of Creative-Infomatics, The University of Tokyo, and Robotics Systems Lab, ETH Zurich
Presented at the 2021 IEEE International Conference on Robotics and Automation (ICRA)
See the full proceedings: ieeexplore.ieee.org/xpl/conhome/9560720/proceeding
#robot #robotics