Uploaded April 2019 | Updated September 2026, 3 weeks ago
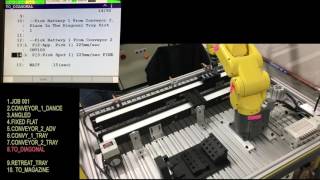
This video shows the completed Capstone project by Schuyler and Johnny. Students started with a basic 5'x5' #80-20 table, developed the idea, designed all tooling, and fixtures. Assembled all mechanical, pneumatic, and electrical systems. All robot, PLC, and HMI programming was completed by students. This proof-of-concept project was completed for Madison College, as a demonstration cell. Regular progress reports, full documentation, and simulated Factory Acceptance Testing had to be completed. To learn more or sign up, visit www.madisoncollege.edu/amst
This video shows the completed Capstone project by Schuyler and Johnny. Students started with a basic 5'x5' #80-20 table, developed the idea, designed all tooling, and fixtures. Assembled all mechanical, pneumatic, and electrical systems. All robot, PLC, and HMI programming was completed by students. This proof-of-concept project was completed for Madison College, as a demonstration cell. Regular progress reports, full documentation, and simulated Factory Acceptance Testing had to be completed. To learn more or sign up, visit www.madisoncollege.edu/amst