Uploaded February 2020 | Updated September 2026, 3 weeks ago
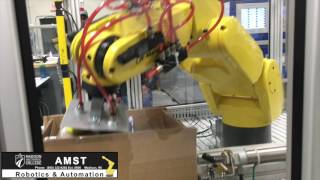
Madison Area Technical College AMST program students demonstrate their capstone project for Pro-Active Engineering. The assembly process includes installing 10 screws and placing 10 labels.
All of the fixtures, tooling, PLC, Robot, & HMI programming was completed by students (Sam H. & Austin L.). Thanks to our supporters and sponsors at YAMAHA, FANUC Robotics, & COGNEX.