Uploaded November 2026 | Updated November 2026, 11 hours ago
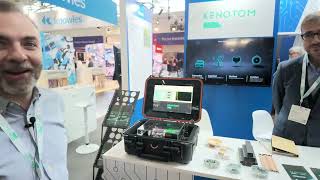
Xentara, the open software-defined automation runtime from embedded ocean in Munich, sits between industrial assets and AI so machines can be orchestrated in one deterministic environment. It runs on real-time Linux with PREEMPT_RT, connecting PLCs, fieldbuses, sensors, robots, cameras, and models through plugin skills. A Siemens S7-1200 is shown using native Siemens Get/Put, and the same engine can reach EtherCAT and CANopen. xentara.io
Each skill is configured in an ASCII JSON file for data points, security, and interfaces, and the Xentara Workbench can import Siemens and Beckhoff vendor files such as .db or .tmc. A no-code mask sits on top of that file, and Xentara Inspector shows how data points behave at runtime. Custom C++ or Rust logic can be written from a dev container, typically connecting Visual Studio Code in about half an hour.
Physical AI here means running model inference at the machine instead of waiting on a delayed cloud report. Model Context Protocol lets an LLM or agent call the Xentara runtime while a timing model keeps event-based decisions from disturbing a cyclic control loop. One motion example closes a deterministic loop in 250 microseconds, with cyclic performance measured up to 100 kHz.
Image processing is appearing in many customer projects because time-series control data and camera frames have to share one low-latency path. A GenICam interface brings industrial cameras into the runtime, and an ONNX path can run vision on CPU or attach a GPU when needed. In brownfield retrofit work, Xentara is the IT/OT bridge for a long-lived line PLC beside newer robots.
Marketing manager Tobias points to a free trial on the Xentara site and to SPS 2026 in Nuremberg, Hall 7, booth 180, where a robot-and-AGV demo can hand merch and a production license after an agent talk that still needs human approval. About 50 skills are in the ecosystem, and the longer aim is an agent-controlled factory you can talk to.
Xentara, the open software-defined automation runtime from embedded ocean in Munich, sits between industrial assets and AI so machines can be orchestrated in one deterministic environment. It runs on real-time Linux with PREEMPT_RT, connecting PLCs, fieldbuses, sensors, robots, cameras, and models through plugin skills. A Siemens S7-1200 is shown using native Siemens Get/Put, and the same engine can reach EtherCAT and CANopen. xentara.io
Each skill is configured in an ASCII JSON file for data points, security, and interfaces, and the Xentara Workbench can import Siemens and Beckhoff vendor files such as .db or .tmc. A no-code mask sits on top of that file, and Xentara Inspector shows how data points behave at runtime. Custom C++ or Rust logic can be written from a dev container, typically connecting Visual Studio Code in about half an hour.
Physical AI here means running model inference at the machine instead of waiting on a delayed cloud report. Model Context Protocol lets an LLM or agent call the Xentara runtime while a timing model keeps event-based decisions from disturbing a cyclic control loop. One motion example closes a deterministic loop in 250 microseconds, with cyclic performance measured up to 100 kHz.
Image processing is appearing in many customer projects because time-series control data and camera frames have to share one low-latency path. A GenICam interface brings industrial cameras into the runtime, and an ONNX path can run vision on CPU or attach a GPU when needed. In brownfield retrofit work, Xentara is the IT/OT bridge for a long-lived line PLC beside newer robots.
Marketing manager Tobias points to a free trial on the Xentara site and to SPS 2026 in Nuremberg, Hall 7, booth 180, where a robot-and-AGV demo can hand merch and a production license after an agent talk that still needs human approval. About 50 skills are in the ecosystem, and the longer aim is an agent-controlled factory you can talk to.