Uploaded April 2016 | Updated September 2026, 1 week ago
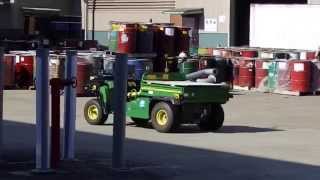
CSIRO's Autonomous John Deere TE Gator is ROS enabled and ready for use. This video is an example of the vehicle and some of the sensing capabilities. This system is capable of being adapted to many different applications.
Please check the related publications:
Ralph Aeschimann and Paulo V. K. Borges “Ground or Obstacles? Detecting clear paths in vehicle navigation,” in IEEE International Conference on Robotics and Automation, Seattle, USA, May, 2015.
Robert Bichsel and Paulo V. K. Borges “Discrete-Continuous clustering for obstacle detection using stereo-vision,” IEEE International Conference on Intelligent Robots and Systems, Hamburg, Germany, September, 2015.
Paulo V. K. Borges and Peyman Moghdam ``Combining Motion and Appearance for Scene Segmentation'', in IEEE International Conference on Robotics and Automation, Hong Kong, China, May, 2014.
Stefan Hoermann and Paulo V. K. Borges ``Vehicle localization and classification using off-board vision and 3-D models,'' IEEE Transactions on Robotics, December, 2013.
Paulo V. K. Borges, Robert Zlot and Ashley Tews, ``Integrating Off-board Cameras and Vehicle On-Board Localization for Pedestrian Safety'', IEEE Transactions on Intelligent Transportation Systems, June, 2013.
Paulo V. K. Borges, Nicola Conci, Andrea Cavallaro ``Video-based human behaviour understanding: a survey,'' IEEE Transactions on Circuits and Systems for Video Technology, May, 2013.
CSIRO's Autonomous John Deere TE Gator is ROS enabled and ready for use. This video is an example of the vehicle and some of the sensing capabilities. This system is capable of being adapted to many different applications.
Please check the related publications:
Ralph Aeschimann and Paulo V. K. Borges “Ground or Obstacles? Detecting clear paths in vehicle navigation,” in IEEE International Conference on Robotics and Automation, Seattle, USA, May, 2015.
Robert Bichsel and Paulo V. K. Borges “Discrete-Continuous clustering for obstacle detection using stereo-vision,” IEEE International Conference on Intelligent Robots and Systems, Hamburg, Germany, September, 2015.
Paulo V. K. Borges and Peyman Moghdam ``Combining Motion and Appearance for Scene Segmentation'', in IEEE International Conference on Robotics and Automation, Hong Kong, China, May, 2014.
Stefan Hoermann and Paulo V. K. Borges ``Vehicle localization and classification using off-board vision and 3-D models,'' IEEE Transactions on Robotics, December, 2013.
Paulo V. K. Borges, Robert Zlot and Ashley Tews, ``Integrating Off-board Cameras and Vehicle On-Board Localization for Pedestrian Safety'', IEEE Transactions on Intelligent Transportation Systems, June, 2013.
Paulo V. K. Borges, Nicola Conci, Andrea Cavallaro ``Video-based human behaviour understanding: a survey,'' IEEE Transactions on Circuits and Systems for Video Technology, May, 2013.