Uploaded October 2024 | Updated September 2026, 2 weeks ago
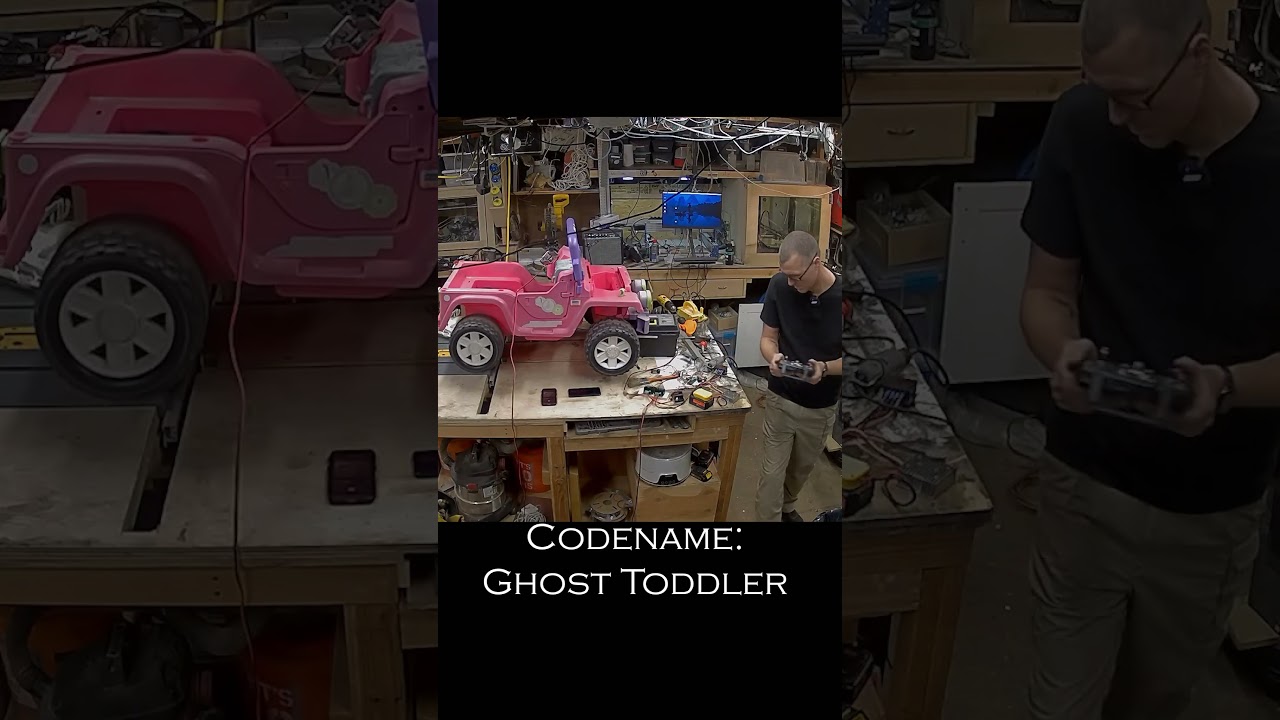
This project uses the Ibus serial protocol from a Flysky RC receiver. That stream is read by an ESP32 over a second uart port, parsed, and converted into meaningful data from the RC transmitter. That data is then used to control two BTS7960 motor drivers for the wheels and a 35kg * cm servo on the steering wheel.
This project uses the Ibus serial protocol from a Flysky RC receiver. That stream is read by an ESP32 over a second uart port, parsed, and converted into meaningful data from the RC transmitter. That data is then used to control two BTS7960 motor drivers for the wheels and a 35kg * cm servo on the steering wheel.


