Uploaded March 2026 | Updated September 2026, 3 weeks ago
What does human-to-robot dexterity transfer look like in 2026?
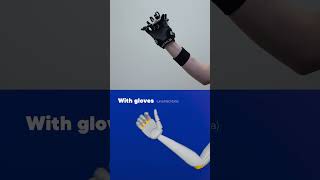
Every finger movement is captured in real time. Hand configurations are mapped directly to simulated robot joint positions.
MANUS gloves are natively supported in NVIDIA Isaac Lab 2.3, purpose-built for dexterous manipulation data collection at scale.
If you're at GTC next week, come find us and try it yourself.
Book a meeting: manus-meta.com/gtc-2026