Uploaded October 2019 | Updated November 2026, 3 hours ago
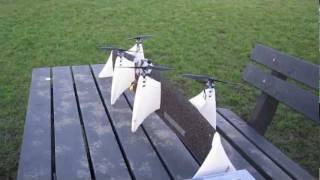
A swarm of tiny flying robots autonomously explores unknown environments. The tiny robots do not make maps of their environment, but deal with obstacles on the fly. In robotics, the algorithms for navigating like this are called "bug algorithms". The navigation of the robots involves them first flying away from the base station and later finding their way back with the help of a wireless beacon.
More details on the navigation solution and the swarm of robots can be found in the following scientific article:
Minimal navigation solution for a swarm of tiny flying robots to explore an unknown environment, K.N. McGuire, C. De Wagter, K. Tuyls, H. Kappen, G.C.H.E. de Croon. Science Robotics.
robotics.sciencemag.org/content/4/35/eaaw9710
This research is a collaboration between the Micro Air Vehicle Lab at TU Delft (http://mavlab.tudelft.nl), the smARTLab at the University of Liverpool (wordpress.csc.liv.ac.uk/smartlab/) and Radboud University (https://www.ru.nl/personen/kappen-h/).
This work was financed by the Dutch Research Council (NWO) grant with number 656.000.006 within the Natural Artificial Intelligence programme.
We greatly appreciate the support of the TU Delft Robotics Institute:
https://tudelftroboticsinstitute.nl/
A swarm of tiny flying robots autonomously explores unknown environments. The tiny robots do not make maps of their environment, but deal with obstacles on the fly. In robotics, the algorithms for navigating like this are called "bug algorithms". The navigation of the robots involves them first flying away from the base station and later finding their way back with the help of a wireless beacon.
More details on the navigation solution and the swarm of robots can be found in the following scientific article:
Minimal navigation solution for a swarm of tiny flying robots to explore an unknown environment, K.N. McGuire, C. De Wagter, K. Tuyls, H. Kappen, G.C.H.E. de Croon. Science Robotics.
robotics.sciencemag.org/content/4/35/eaaw9710
This research is a collaboration between the Micro Air Vehicle Lab at TU Delft (http://mavlab.tudelft.nl), the smARTLab at the University of Liverpool (wordpress.csc.liv.ac.uk/smartlab/) and Radboud University (https://www.ru.nl/personen/kappen-h/).
This work was financed by the Dutch Research Council (NWO) grant with number 656.000.006 within the Natural Artificial Intelligence programme.
We greatly appreciate the support of the TU Delft Robotics Institute:
https://tudelftroboticsinstitute.nl/