Uploaded May 2026 | Updated September 2026, 2 weeks ago
For more information about Stanford’s graduate programs, visit: https://online.stanford.edu/graduate-education
May 1, 2026
This seminar covers:
• Learning and control for multi-agent interactions
• Game-theoretic planning and control for robots
• Learning in interactive domains, including imitation learning and reinforcement learning
Follow along with the seminar schedule, visit: stanfordasl.github.io/robotics_seminar
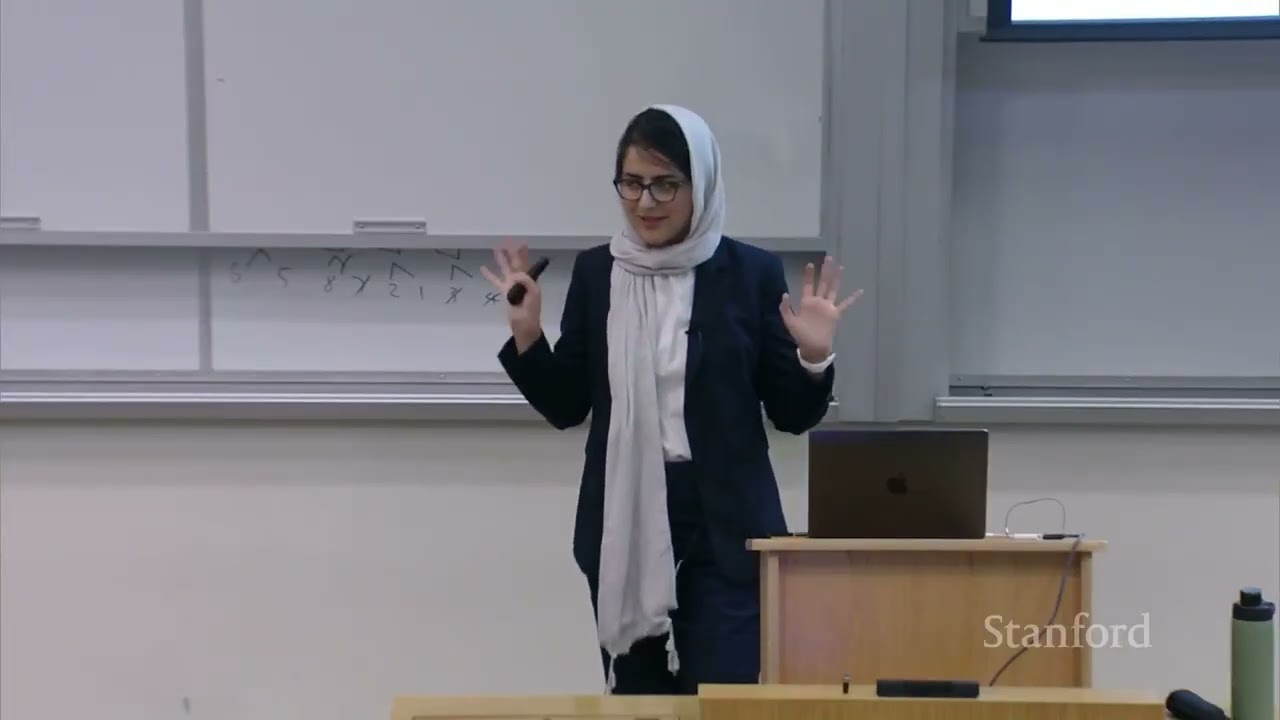
Negar Mehr is an assistant professor in the Mechanical Engineering Department at the University of California at Berkeley. She runs the ICON Lab.
For more information about Stanford’s graduate programs, visit: https://online.stanford.edu/graduate-education
May 1, 2026
This seminar covers:
• Learning and control for multi-agent interactions
• Game-theoretic planning and control for robots
• Learning in interactive domains, including imitation learning and reinforcement learning
Follow along with the seminar schedule, visit: stanfordasl.github.io/robotics_seminar
Negar Mehr is an assistant professor in the Mechanical Engineering Department at the University of California at Berkeley. She runs the ICON Lab.