Uploaded July 2021 | Updated September 2026, 1 week ago
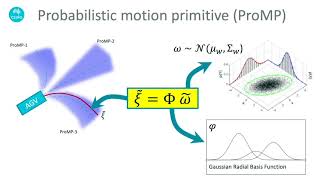
Paper: Tobias Low, Tirthankar Bandyopadhyay, Jason Williams, Paulo V K Borges, "PROMPT: Probabilistic Motion Primitives based Trajectory Planning" in Robotics: Science and Systems, 2021.

![[RA-L/ICRA 2018] Complementary Perception for Handheld SLAM
We present a novel method for mapping general 3D environments, where sufficient geometric or visual information is not everywhere guaranteed and where the device motion is unconstrained as with handheld systems. The continuous-time SLAM algorithm integrates a lidar, camera and inertial measurement unit in a complementary fashion whereby all sensors contribute constraints to the optimization. The proposed algorithm is designed to expand the domain of mappable environments and therefore increase the reliability and utility of general purpose mobile mapping. A key component of the proposed algorithm is the incorporation of depth uncertainty into visual features, which is effective for noisy surfaces and allows features with and without depth estimates to be modeled in a unified manner. Results demonstrate a wider mappable domain on challenging environments compared to state-of-the-art lidar or vision based localization and mapping algorithms. [RA-L/ICRA 2018] Complementary Perception for Handheld SLAM](https://i.ytimg.com/vi/q8NAsqOH2C0/mqdefault.jpg)


![[RAL2025] Video Foundation Models to Enhance Intermittent Supervision
K. Katuwandeniya, L. Tian and D. Kulić, ‘What Did the Robot Do in My Absence?’ Video Foundation Models to Enhance Intermittent Supervision, in IEEE Robotics and Automation Letters, vol. 10, no. 4, pp. 3222-3229, April 2025, doi: 10.1109/LRA.2025.3539118.
For more information, please check out the project website: https://kavindie.github.io/what-did-the-robot-do-in-my-absence/ [RAL2025] Video Foundation Models to Enhance Intermittent Supervision](https://i.ytimg.com/vi/sLUD1xTIeFs/mqdefault.jpg)


![[IROS2021] CatChatter: Acoustic Perception for Mobile Robots
There are many examples in nature of animals using acoustics to understand and navigate the world around them. Inspired by this, we train an image-to-image translation network to learn the mapping from recorded chirps and echos from an environment to a 360 degree depth map of the environment. This work is focused on expanding on the capabilities of previously published BatVision in a number of ways. We first propose various methods for data augmentation to help the model generalise on less data. We also propose changes to the model architecture to improve performance and training stability. Finally, we investigate the feasibility of 360 degree scene reconstruction by using more microphones and lidar based 3D SLAM data as ground truth for training the model.
You can find the full IEEE RA-L paper here: https://ieeexplore.ieee.org/document/9472944 [IROS2021] CatChatter: Acoustic Perception for Mobile Robots](https://i.ytimg.com/vi/uLSE8__TCHQ/mqdefault.jpg)