Robot Axes Explained | Degrees of Freedom, Pitch, Roll and Yaw @engineeringtechsims
Robot Axes Explained | Degrees of Freedom, Pitch, Roll and Yaw  @engineeringtechsims
Uploaded June 2015 | Updated November 2026, 3 hours ago
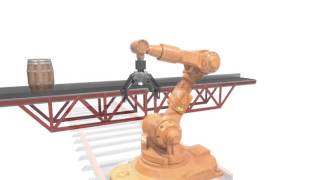
This video explains how robot motion is described using axes and degrees of freedom. It distinguishes position axes at the waist, shoulder, and elbow from wrist orientation axes, then shows how pitch, roll, and yaw orient the tool relative to the workpiece. Useful for robotics and industrial automation students.
Robot Axes Explained | Degrees of Freedom, Pitch, Roll and YawTypes of Hydraulic Pumps Explained | Gear, Vane and Piston Pump Basics #ShortsMemory Technology Explained | Writing and Reading 4-Bit Binary DataWhat Is an AC Motor? | Engineering BasicsFluid Power Design Basics | Cylinder Force, Speed and Motor TorqueDigital-to-Analog Converters Explained | Resistor Network and Summing Op-AmpBinary to Decimal Conversion ExplainedPressure Measurements Explained | Absolute, Gauge and Vacuum PressureHow to Read Resistor Color Codes | 4-Band Resistor Values and ToleranceWhat does a Half-wave Rectifier do? | Engineering BasicsRobotics Risk Assessment: Recognizing Potential Hazards ExplainedHow to Solve RLC Circuits | Series and Parallel Circuit Calculations
Engineering Technology Simulation Learning Videos |

Robot Axes Explained | Degrees of Freedom, Pitch, Roll and Yaw

SHARE TO X SHARE TO REDDIT SHARE TO FACEBOOK WALLPAPER