Uploaded December 2020 | Updated November 2026, 3 days ago
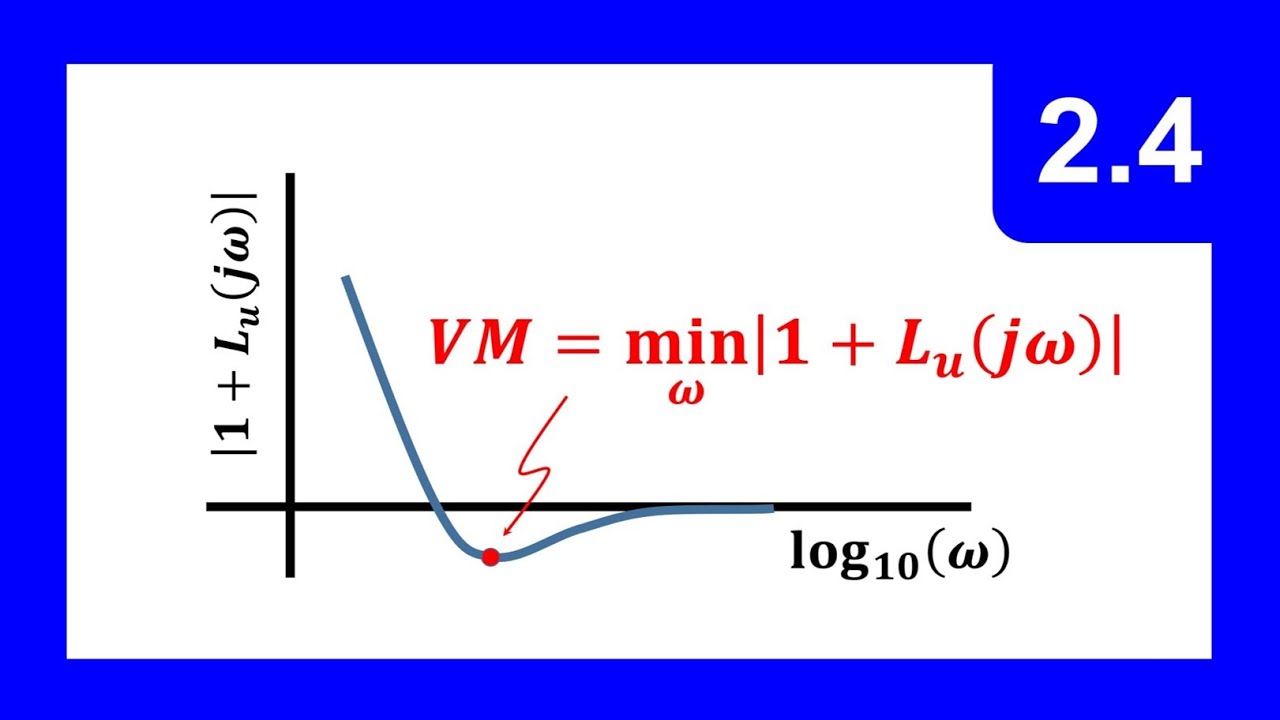
A closed loop system can be very near instability while gain and phase margins meet design criteria. In this video we motivate this situation and introduce the return difference transfer function. To avoid being mislead by gain and phase margins, vector margin is introduced. Rules of thumb for gain, phase, and vector margin design values are provided.
A closed loop system can be very near instability while gain and phase margins meet design criteria. In this video we motivate this situation and introduce the return difference transfer function. To avoid being mislead by gain and phase margins, vector margin is introduced. Rules of thumb for gain, phase, and vector margin design values are provided.


