Uploaded March 2017 | Updated November 2026, 3 hours ago
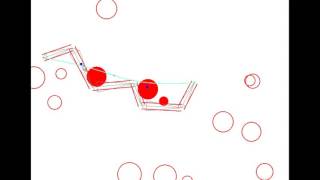
This is a program that I am starting to work on that tests out an idea that I had recently about how to intelligently manipulate a robot arm so that it can avoid obstacles and try to maintain the joints near their default angle.
This is a program that I am starting to work on that tests out an idea that I had recently about how to intelligently manipulate a robot arm so that it can avoid obstacles and try to maintain the joints near their default angle.