Uploaded June 2022 | Updated September 2026, 1 hour ago
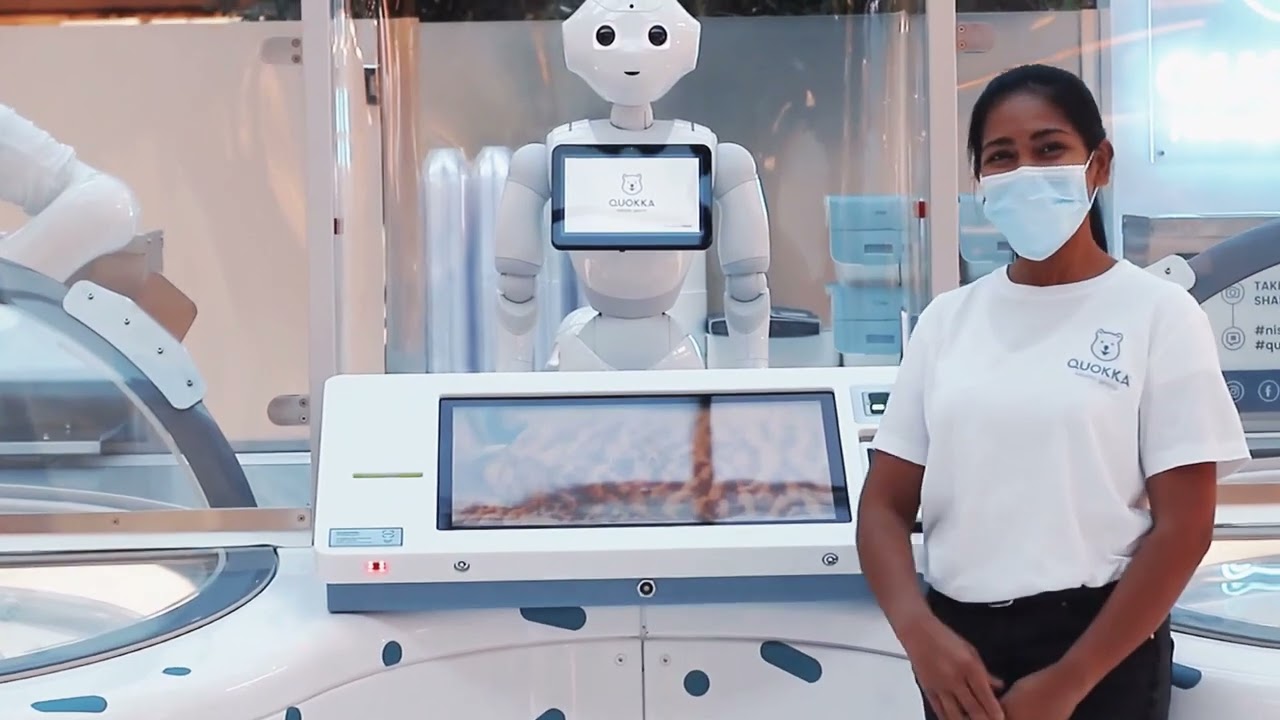
QUOKKA, a local UAE-based company, has partnered with NISKA Retail Robotics, an Australian-born tech start-up, to open the first ice cream bar entirely staffed by robots.
The store is present inside the premises of Marina Mall, Abu Dhabi (UAE). Our Master Distributor in the Gulf region, Jacky’s, has worked along with NISKA’s technical team to integrate their solution with Pepper.
#pepper #quokka #niskaretailrobotics #jackys #softbankroboticseurope #aldebaran #unitedroboticsgroup #icecream #gelato #uae #abudhabi #marinamall
QUOKKA, a local UAE-based company, has partnered with NISKA Retail Robotics, an Australian-born tech start-up, to open the first ice cream bar entirely staffed by robots.
The store is present inside the premises of Marina Mall, Abu Dhabi (UAE). Our Master Distributor in the Gulf region, Jacky’s, has worked along with NISKA’s technical team to integrate their solution with Pepper.
#pepper #quokka #niskaretailrobotics #jackys #softbankroboticseurope #aldebaran #unitedroboticsgroup #icecream #gelato #uae #abudhabi #marinamall




![[Atalk] Oliver Brock - Variability : The main obstacle for general robotics? 2/2
Abstract:
The biggest success story of robotics remains factory automation. But our field is struggling to repeat this success in any other domain, especially in domains we call unstructured. Among the main culprits for this difficulty have been uncertainty and the high-dimensionality of configuration spaces associated with versatile robots. In my talk, I will argue that our field has found successful solutions for uncertainty and high-dimensionality, as long as they pertain to the robot itself. I will argue that after alleviating these two problems, a new problem has become the next bottleneck: the variability of the environment. On our path towards general robotics, we must focus on handling this variability. This might seem completely obvious, but I believe the most important implications of this realization have been largely ignored. I will present some attempts to address the variability in the environment, including interactive perception and learning with robotic priors. I will also place these solutions in the context of other attempts to address variability, such as big data and deep learning.
Bio:
Oliver Brock is the Alexander-von-Humboldt Professor of Robotics in the School of Electrical Engineering and Computer Science at the Technische Universität Berlin in Germany. He received his Diploma in Computer Science in 1993 from the Technische Universität Berlin and his Masters and Ph.D. in Computer Science from Stanford University in 1994 and 2000, respectively. He also held post-doctoral positions at Rice University and Stanford University. Starting in 2002, he was an Assistant Professor and Associate Professor in the Department of Computer Science at the University of Massachusetts Amherst, before to moving back to the Technische Universität Berlin in 2009. The research of Brocks lab, the Robotics and Biology Laboratory, focuses on autonomous mobile manipulation, interactive perception, grasping, manipulation, soft hands, interactive learning, motion generation, and the application of algorithms and concepts from robotics to computational problems in structural molecular biology. He is also the president of the Robotics: Science and Systems foundation. [Atalk] Oliver Brock - Variability : The main obstacle for general robotics? 2/2](https://i.ytimg.com/vi/Q7L08BNsjqg/mqdefault.jpg)