Uploaded April 2024 | Updated September 2026, 2 hours ago
Microsoft Future Leaders in Robotics and AI Seminar Series: Minimal Perception: Enabling Autonomy in Palm-Sized Robots
Online Seminar
Chahat Deep Singh
Postdoctoral Fellow
University of Maryland
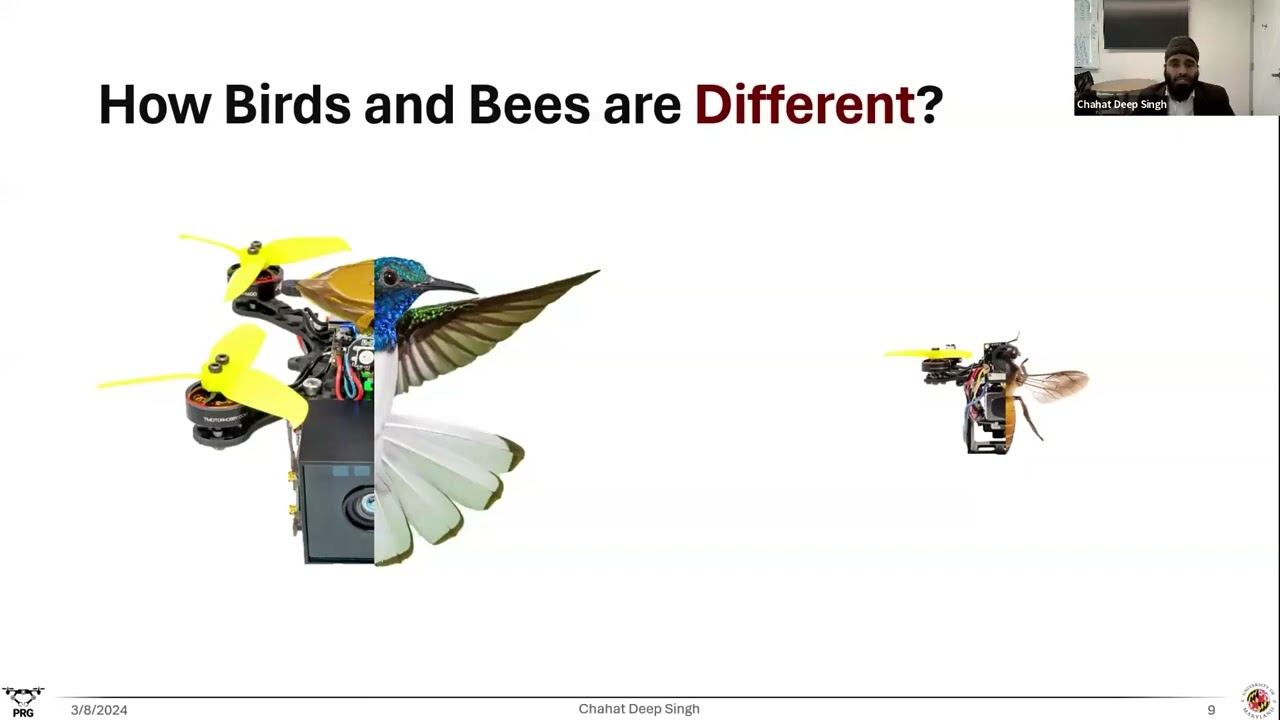
Perception plays a vital role in living beings and robots alike. These perception frameworks are essential for their autonomous behaviors for environmental understanding and interaction. Although, we have seen the boom of artificial intelligence, autonomy in palm-sized robots is still nascent. These robots face limitations in real-time perception due to computing, power, and sensing constraints. Drawing inspiration from small living beings such and insects and hummingbirds that are known for their sophisticated perception, navigation and survival capabilities, I propose a Minimal Perception framework that aims to provide insights into designing compact and efficient perception systems for resource-constrained autonomy, using only onboard sensing and computation at scales that were never thought possible before. The solution to robot autonomy lies at the intersection of AI, computer vision, computational imaging and robotics -- resulting in minimal robots. This talk explores the challenge of developing a minimal perception framework for tiny robots (less than 6 inches) used in field operations such as space inspections in confined spaces and robot pollination. Furthermore, we will delve into the realm of selective perception, embodied AI, and the future of robot autonomy in the palm of your hands.
For more information on the Maryland Robotics Center see:
https://robotics.umd.edu
Microsoft Future Leaders in Robotics and AI Seminar Series: Minimal Perception: Enabling Autonomy in Palm-Sized Robots
Online Seminar
Chahat Deep Singh
Postdoctoral Fellow
University of Maryland
Perception plays a vital role in living beings and robots alike. These perception frameworks are essential for their autonomous behaviors for environmental understanding and interaction. Although, we have seen the boom of artificial intelligence, autonomy in palm-sized robots is still nascent. These robots face limitations in real-time perception due to computing, power, and sensing constraints. Drawing inspiration from small living beings such and insects and hummingbirds that are known for their sophisticated perception, navigation and survival capabilities, I propose a Minimal Perception framework that aims to provide insights into designing compact and efficient perception systems for resource-constrained autonomy, using only onboard sensing and computation at scales that were never thought possible before. The solution to robot autonomy lies at the intersection of AI, computer vision, computational imaging and robotics -- resulting in minimal robots. This talk explores the challenge of developing a minimal perception framework for tiny robots (less than 6 inches) used in field operations such as space inspections in confined spaces and robot pollination. Furthermore, we will delve into the realm of selective perception, embodied AI, and the future of robot autonomy in the palm of your hands.
For more information on the Maryland Robotics Center see:
https://robotics.umd.edu