Uploaded July 2018 | Updated September 2026, 21 minutes ago
#Drone #Controller #UAVControl #ModelBasedDesign
Hi Everyone,
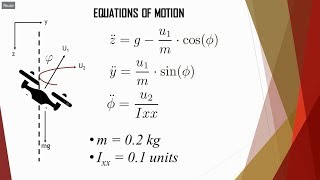
In this video I walk you through designing and implementing a 2D linear controller for a quad rotor moving along a specified trajectory.
The quad is commanded to move across a trajectory defined as a function of time x(t), z(t). The equations of motion are first linearized and then implemented in Simulink.
This tutorial covers the following fundamental control concepts
1) Linearization
2) Under-actuation
3) Coupling
4) PID/PD/PI control
5) Tuning
6) Inner Loop Control
Feel free to leave your feedback below.
For more videos like this, tutorials, and tips & tricks, subscribe to this channel at:
youtube.com/user/vinayak678MATLABSimulink
Best Wishes
VDEngineering
~~My Udemy Courses on Motion Planning / Navigation / Trajectory Planning:
udemy.com/course/autonomous-robots-nonholonomic-motion-planning-algorithms
My Instagram: instagram.com/vinayak_desh
Buy Coffee: buymeacoffee.com/vdengineering
My Website: vinayakd.com
#Drone #Controller #UAVControl #ModelBasedDesign
Hi Everyone,
In this video I walk you through designing and implementing a 2D linear controller for a quad rotor moving along a specified trajectory.
The quad is commanded to move across a trajectory defined as a function of time x(t), z(t). The equations of motion are first linearized and then implemented in Simulink.
This tutorial covers the following fundamental control concepts
1) Linearization
2) Under-actuation
3) Coupling
4) PID/PD/PI control
5) Tuning
6) Inner Loop Control
Feel free to leave your feedback below.
For more videos like this, tutorials, and tips & tricks, subscribe to this channel at:
youtube.com/user/vinayak678MATLABSimulink
Best Wishes
VDEngineering
~~My Udemy Courses on Motion Planning / Navigation / Trajectory Planning:
udemy.com/course/autonomous-robots-nonholonomic-motion-planning-algorithms
My Instagram: instagram.com/vinayak_desh
Buy Coffee: buymeacoffee.com/vdengineering
My Website: vinayakd.com