Uploaded January 2020 | Updated September 2026, 2 weeks ago
If you like this video and want to support me, go this page for my donation Paypal or crypto addresses:
youtube.com/c/mobilefish/about
This is part 48 of the LoRa/LoRaWAN tutorial.
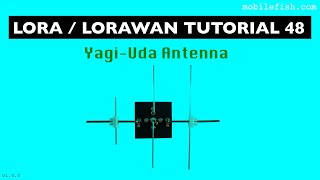
In this tutorial I will explain what a Yagi-Uda antenna is and how to build one.
The Yagi-Uda antenna, also known as Yagi antenna, is a directional high gain antenna.
A basic Yagi-Uda antenna consists of three elements.
A reflector, a driven element and a director.
The driven element is a half wave dipole and parallel to the driven element on either side of it, are straight wires, the reflector and the director.
The reflector is slightly longer than 1/2 wavelength, the driven element is 1/2 wavelength long and the director is slightly shorter than 1/2 wavelength.
I used an online Yagi-Uda antenna calculator to calculate the antenna dimensions:
rfwireless-world.com/calculators/3-element-Yagi-Antenna-Calculator.html
I have used the 4NEC2 antenna modelling software to verify the design.
mobilefish.com/download/lora/yagi_868mhz_4nec2_before_optimisation.nec.txt
Next I used the 4NEC2 optimising functionality to improve the design.
mobilefish.com/download/lora/yagi_868mhz_4nec2_after_optimisation.nec.txt
Performance test A:
The Yagi-Uda antenna is attached to an end node, which is located inside a building, and transmit messages which will be received by nearby gateways in my area.
In this test I am only interested which gateways were able to receive the transmitted sensor data.
The test will be repeated using a sleeve dipole antenna.
Performance test B:
The Yagi-Uda antenna is attached to an end node and transmit messages which will be received by a dedicated gateway 6 meters away.
Both devices are indoors.
The average RSSI is calculated and also the total time it took to receive 15 messages.
The test will be repeated using a ½λ dipole antenna.
Performance test A and B are simple tests and will give me a ROUGH INDICATION how well my antenna performs compared to the dipole antenna.
Both tests are conducted indoors which means the walls reflects the transmitted signals thus influencing the measurements.
Therefore take the results with a grain of salt!
A much better method to tell how your antenna actually performs in the real world, see this procedure:
github.com/LoRaTracker/AntennaTesting
Performance test A:
The Yagi-Uda antenna performance is compared with a sleeve dipole antenna.
More information about sleeve dipole antennas, see tutorial 43.
For this test I am using the end node and antenna C as demonstrated in tutorial 33.
More information about this end node, see:
mobilefish.com/developer/lorawan/lorawan_quickguide_build_lora_node_rfm95_arduino_pro_mini.html
The end node uses the MCCI LoRaWAN LMIC Library:
github.com/mcci-catena/arduino-lmic
The end node uses the following sketch:
mobilefish.com/download/lora/ttn-otaa-pro-mini-sensors.ino.txt
I have NOT modified the end node transmission power when using the Yagi-Uda antenna.
In my area there are several gateways and I know that these gateways, which are connected to The Things Network, can receive my transmitted data.
The Yagi-Uda antenna is attached to the end node at location A and transmits data.
I have done the same with the sleeve dipole antenna.
In both cases two messages per minute were transmitted.
The logged data can be found at:
mobilefish.com/download/lora/yagi_uda_test_results.txt
One or more gateways were able to receive my transmitted sensor data, see:
drive.google.com/open?id=18SKbHVEIFHU6YjzYpgZL98vuHcmV4OPQ&usp=sharing
Performance test B:
Make sure you keep everything in your setup the same when switching from the Yagi-Uda antenna to the ½λ dipole antenna.
The logged data can be found at:
mobilefish.com/download/lora/yagi_uda_antenna_gain.txt
The average RSSI when using the ½λ dipole antenna: -28.0 dBm
The average RSSI when using the Yagi-Uda antenna: -22.1 dBm
The time it took for the gateway to receive the 15 messages from the end node:
Using the ½λ dipole antenna: 15 minutes
Using the Yagi-Uda antenna: 15 minutes
The Arduino sketch is configured to transmit 1 message per minute.
Conclusion:
Based on the average RSSI test results and the results from performance test A, the Yagi-Uda antenna performs better compared to the sleeve dipole antenna.
but the Yagi-Uda antenna is a directional antenna, you need to point it to the correct direction.
The sleeve dipole antenna is an omnidirectional antenna.
Check out all my other LoRa/LoRaWAN tutorial videos:
youtube.com/playlist?list=PLmL13yqb6OxdeOi97EvI8QeO8o-PqeQ0g
Subscribe to my YouTube channel:
youtube.com/channel/UCG5_CT_KjexxjbgNE4lVGkg?sub_confirmation=1
The presentation used in this video tutorial can be found at:
mobilefish.com/developer/lorawan/lorawan_quickguide_tutorial.html
#mobilefish #lora #lorawan