Uploaded September 2026 | Updated November 2026, 3 hours ago
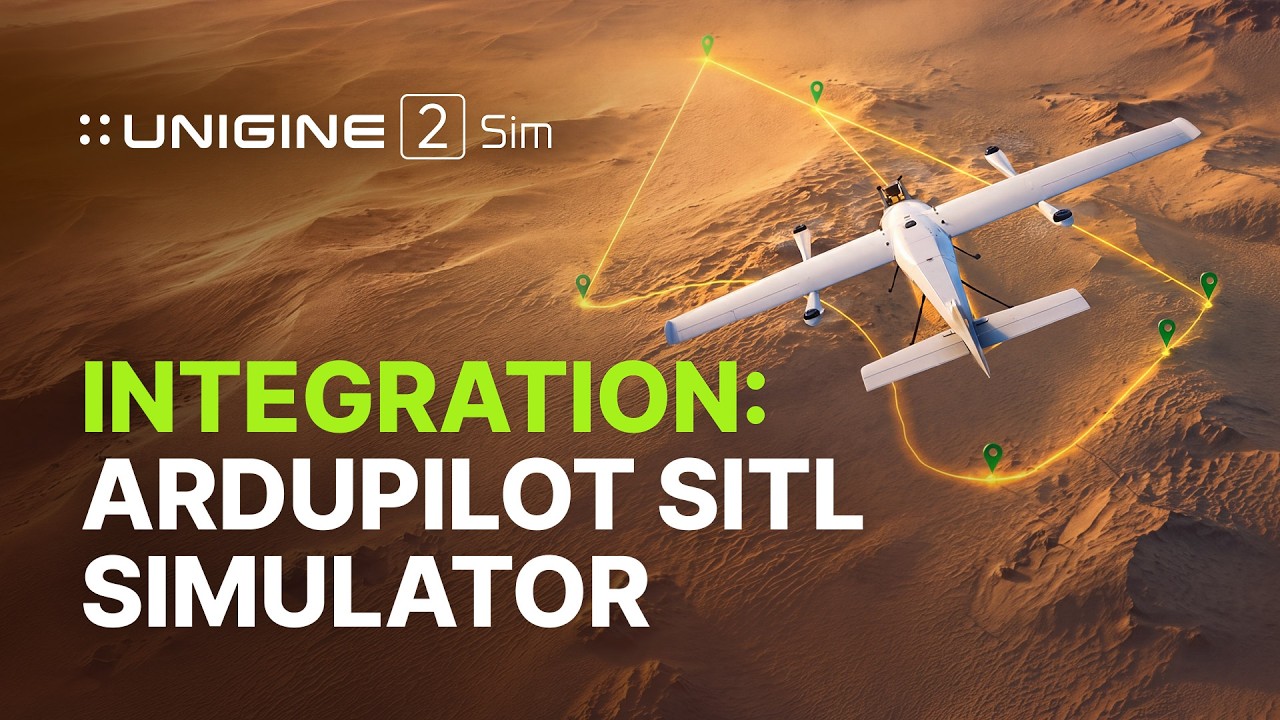
Powered by UNIGINE 2 Sim: ArduPilot SITL (Software in the Loop) integration in the UAV Template:
- Full ArduPilot control stack running natively on your PC
- UNIGINE as the external physics engine: airframe, world, sensor data
This also enables support for any MAVLink ground station: Mission Planner, QGroundControl, MAVProxy
Details: https://l.unigine.com/xpIVweuf22
0:00 Intro
0:05 Autonomous take-off & control
0:16 Waypoint placement via Mission Planner
0:20 Take-off/landing points and altitude planning
0:23 Uploading mission to drone memory
0:25 Launching the mission
0:32 Simulated wind conditions
0:44 eVTOL Aircraft
0:50 Flying to coordinates
0:56 Simulating a variety of onboard sensors
1:06 Manual flight parameters
1:11 Environment collision detection
1:24 Outro
Powered by UNIGINE 2 Sim: ArduPilot SITL (Software in the Loop) integration in the UAV Template:
- Full ArduPilot control stack running natively on your PC
- UNIGINE as the external physics engine: airframe, world, sensor data
This also enables support for any MAVLink ground station: Mission Planner, QGroundControl, MAVProxy
Details: https://l.unigine.com/xpIVweuf22
0:00 Intro
0:05 Autonomous take-off & control
0:16 Waypoint placement via Mission Planner
0:20 Take-off/landing points and altitude planning
0:23 Uploading mission to drone memory
0:25 Launching the mission
0:32 Simulated wind conditions
0:44 eVTOL Aircraft
0:50 Flying to coordinates
0:56 Simulating a variety of onboard sensors
1:06 Manual flight parameters
1:11 Environment collision detection
1:24 Outro