Uploaded April 2024 | Updated September 2026, 3 weeks ago
M. Singh, M. Dharmadhikari, and K. Alexis, "An Online Self-calibrating Refractive Camera Model with Application to Underwater Odometry", IEEE ICRA 2024
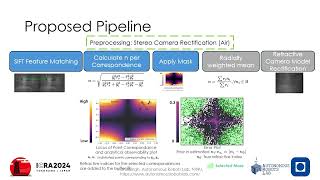
Abstract: This work presents a camera model for refractive media such as water and its application in underwater visual-inertial odometry. The model is self-calibrating in real-time and is free of known correspondences or calibration targets. It is separable as a distortion model (dependent on refractive index n and radial pixel coordinate) and a virtual pinhole model (as a function of n). We derive the self-calibration formulation leveraging epipolar constraints to estimate the refractive index and subsequently correct for distortion. Through experimental studies using an underwater robot integrating cameras and inertial sensing, the model is validated regarding the accurate estimation of the refractive index and its benefits for robust odometry estimation in an extended envelope of conditions. Lastly, we show the transition between media and the estimation of the varying refractive index online, thus allowing computer vision tasks across refractive media.
M. Singh, M. Dharmadhikari, and K. Alexis, "An Online Self-calibrating Refractive Camera Model with Application to Underwater Odometry", IEEE ICRA 2024
Abstract: This work presents a camera model for refractive media such as water and its application in underwater visual-inertial odometry. The model is self-calibrating in real-time and is free of known correspondences or calibration targets. It is separable as a distortion model (dependent on refractive index n and radial pixel coordinate) and a virtual pinhole model (as a function of n). We derive the self-calibration formulation leveraging epipolar constraints to estimate the refractive index and subsequently correct for distortion. Through experimental studies using an underwater robot integrating cameras and inertial sensing, the model is validated regarding the accurate estimation of the refractive index and its benefits for robust odometry estimation in an extended envelope of conditions. Lastly, we show the transition between media and the estimation of the varying refractive index online, thus allowing computer vision tasks across refractive media.